Building an EDF to Fly with FPV Head Tracking

telnar1236

Master member
With my almost year long journey into improving the aerodynamics of EDFs coming to a close with the laminar flow wing Super Duper Sabre starting to have some more sucessful test flights and the Rapier using its BLI design to hit 133 mph with a 4s 64mm setup, I'm finding myself in need of a new project. For a while, I've thought it would be cool to be able to fly an EDF as if I was in the cockpit, something like in this video.


However, I don't want to need to take a big $600 EDF and add another $600 of FPV equipment to it, like these planes are doing since that's a lot of money and given that I have less experience with FPV than with LOS flying I'm going to crash and need to repair my plane at some point which makes it even more money potentially. Those big 90mm EDFs also don't really do what I want an FPV jet to do - I want much longer flight times and to have good low speed handling to make it easier to land under the hood. And while I do want something aerobatic, I don't need F-16 or F-22 levels of maneuverability or speed since I expect I'll spend a lot more of my time cruising and looking out the windows than I will performing aggressive maneuvers.

So, I'm thinking I want to design a fairly small 4s 70mm plane that can still carry a good gimbal and camera while also remaining small and light enough to be easy to transport and fly. The goal is to be able to fly on 1-2 4s 4000 mAh packs which should give me 5 and 10 minutes of flight time respectively, maybe more if I'm keeping the throttle fairly low. I want a max takeoff weight with both packs of 1800g which, with 1500g of thrust should give me reasonable if not great performance. Using the streamlining tricks I've spent the last year figuring out (or scaling down from full scale really), 85-90 mph should be possible.

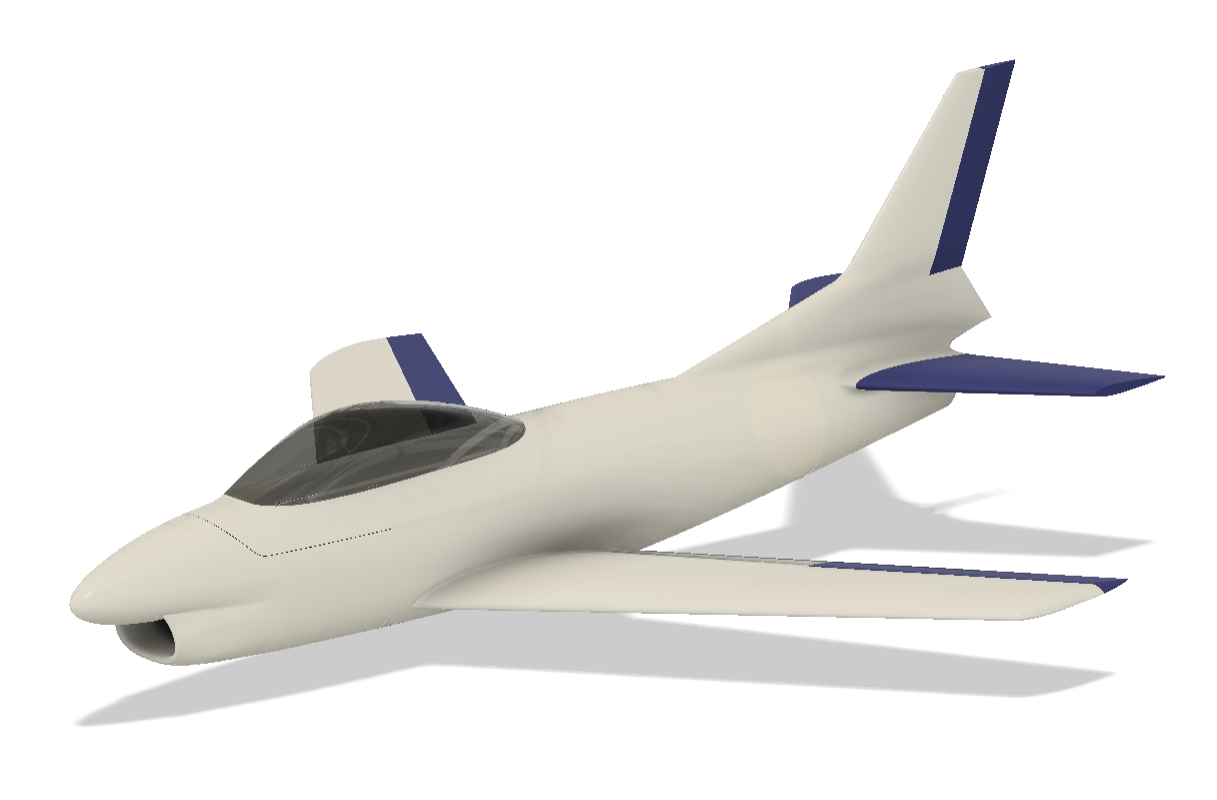
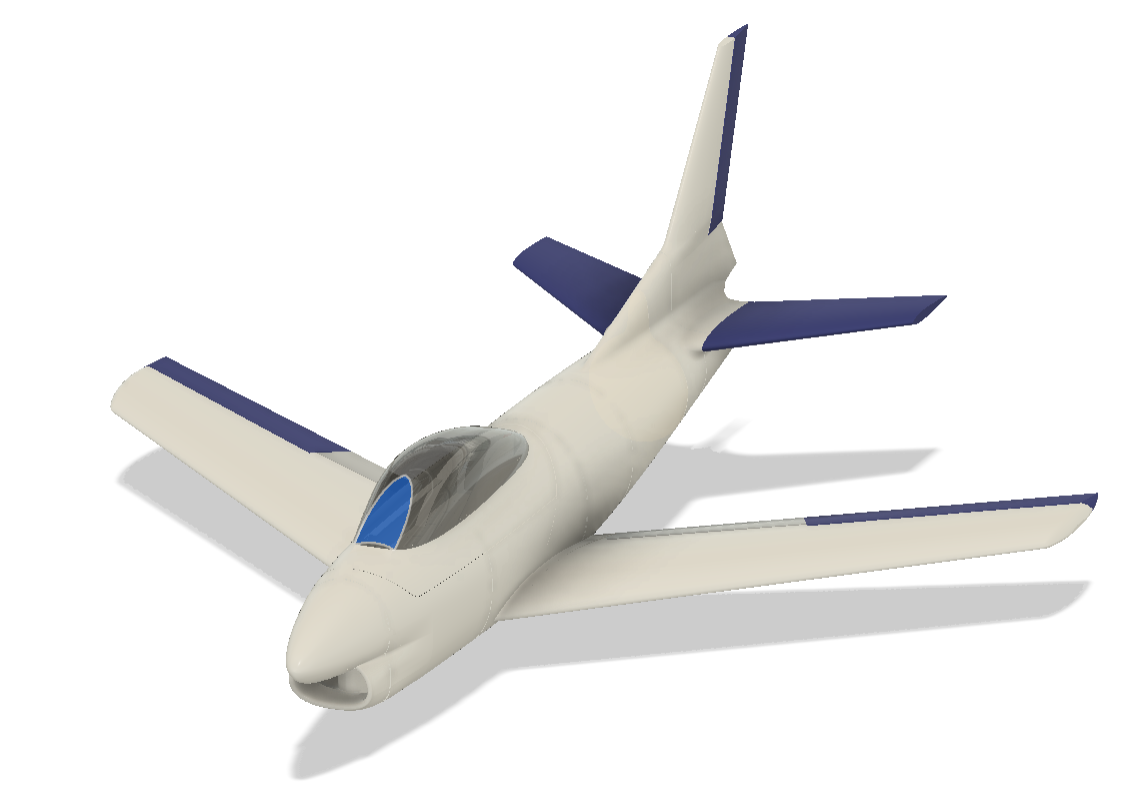
I'm thinking of making the airframe an F-86D SabreDog. It gives a ton of internal space while still being pretty streamlined.
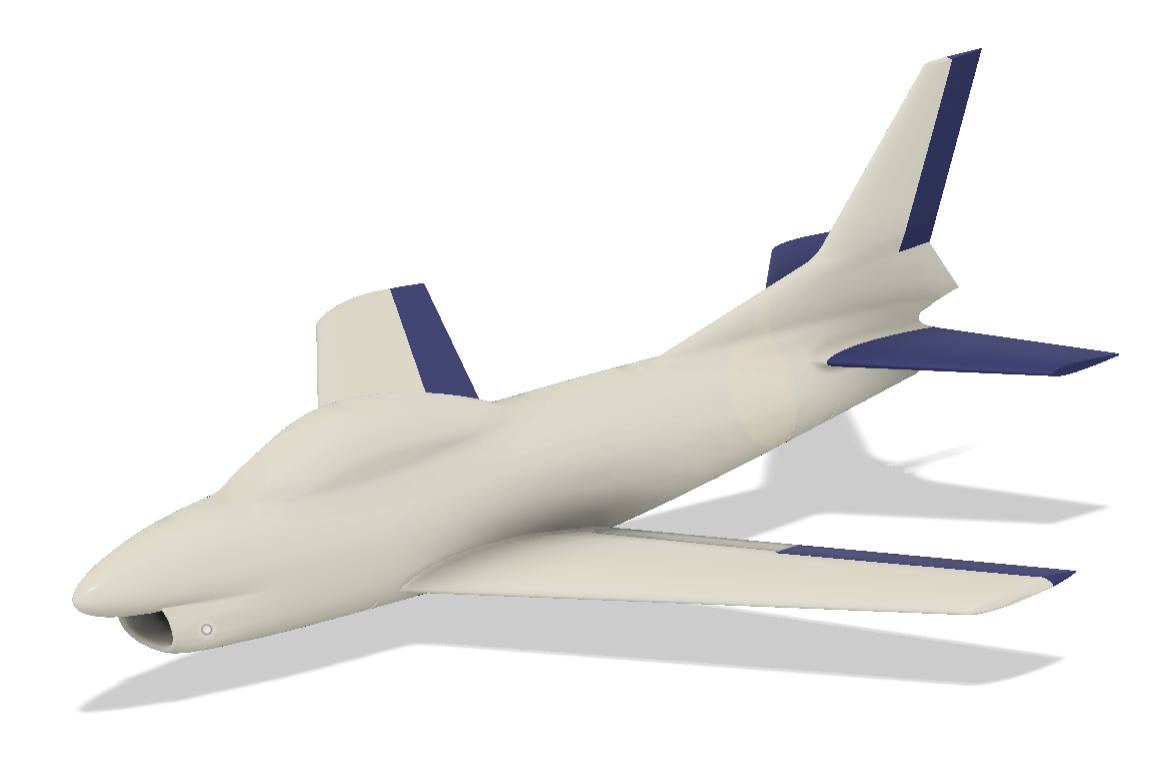
1786328545763.png
 

telnar1236

Master member
I think my first step for this project will actually be to modify a plane I already have to carry FPV gear. Right now, my experience with FPV on jets mostly amounts to strapping a fixed analog camera to a small 50mm EDF and hoping for the best, so I don't really know what I'm going to want in terms of cockpit layout (how high or low to mount the camera, if I want to figure out how to make screens to display battery voltage, etc.) or how much weight to give to different flight characteristics I could design for.

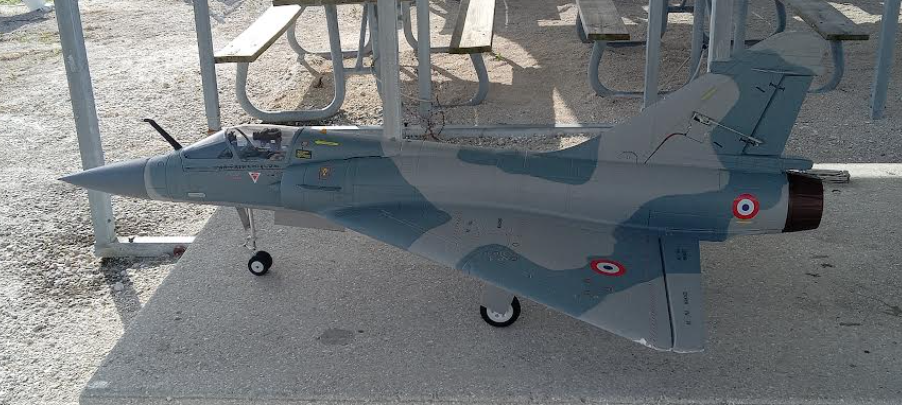
I'm thinking of using either the Falcata which is my most recent 64mm EDF, or my old beat up Freewing Mirage 2000 as the test bed. The Falcata flies very well, has plenty of internal volume, and in most respects would be the perfect plane to learn with, but it's relatively small as a 64mm EDF and doesn't have a ton of excess power so adding an extra 100-200g of weight for the FPV system and cockpit might be a bit much. It's also fairly easy to get behind the power curve on landing and sink a bit too fast which can damage the gear, and the flight times are only average. On the other hand, the Mirage is probably not the ideal jet to learn on since it lands fast and the trim changes every single flight, but it's also tough, basically impossible to stall, and has a ton of excess power. The gear is quite tough, so I'm not too worried about destroying it with bad landings, but it doesn't have much internal volume to play with when it comes to mounting the camera.

The Mirage 2000 is definitely the easier option since it already has a clear windows on the canopy so I don't need to vacuum form a new one and the cockpit has an inside so I don't need to design one, so I'll most likely go with that, but with how fast and squirrelly it can get, I might need to add a gyro or do something to tame it at least a bit for FPV.
 

telnar1236

Master member
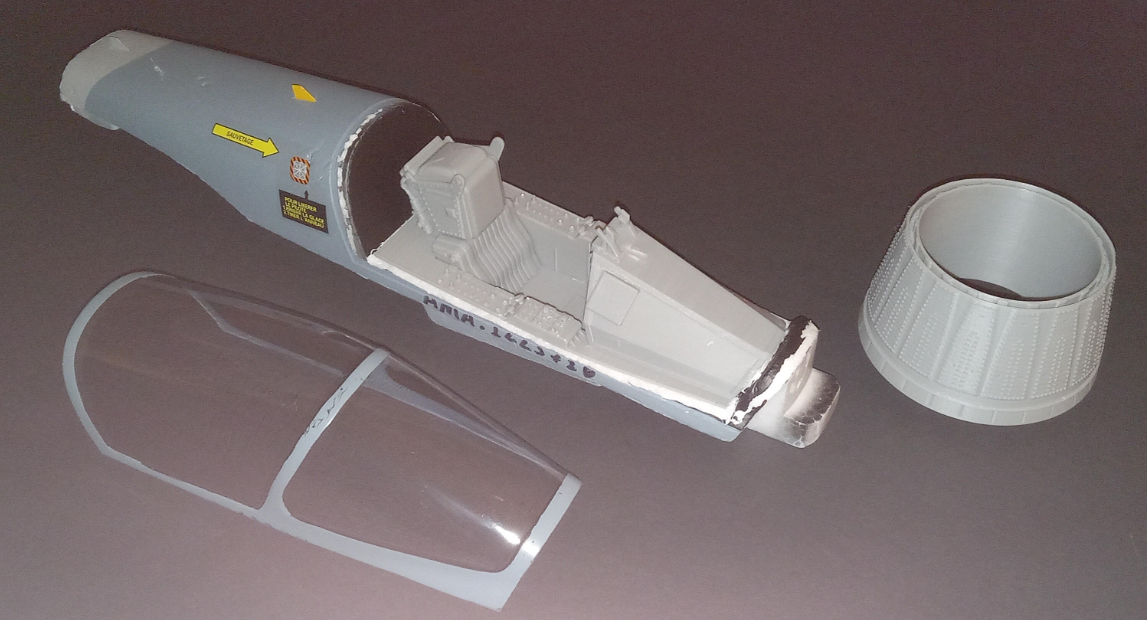
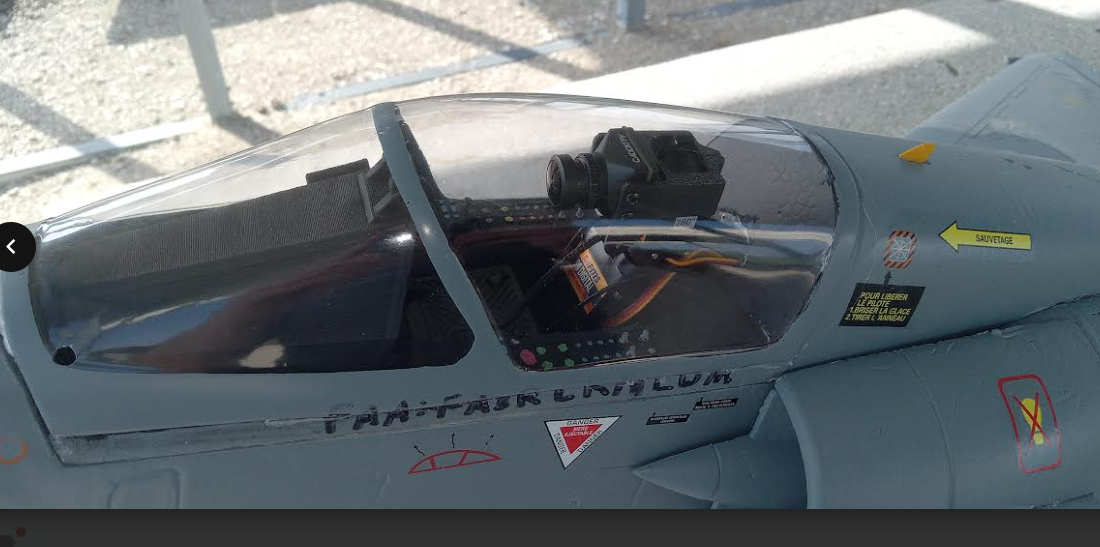
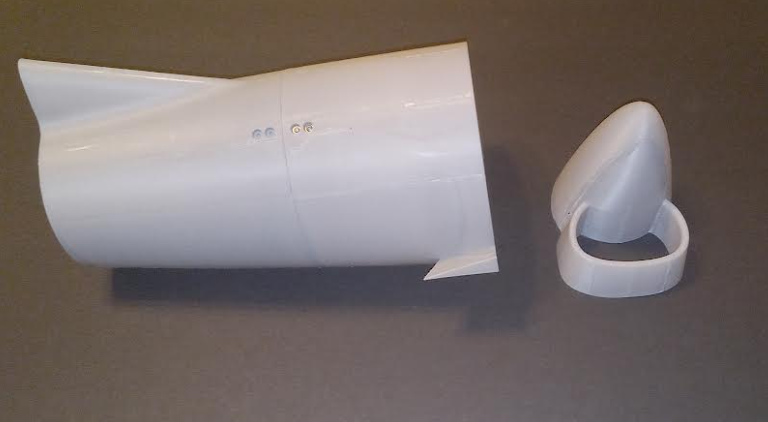
Step one of the FPV conversion of the Mirage is to prepare the cockpit, and this is also where I learned the first big lesson from the Mirage. I spent a while polishing the canopy today to try and get it as clear as possible so I can keep it when I fit the FPV camera which was slow, painful, and only somewhat effective. I think it's good enough but haven't yet fitted the camera to try it. I also found some files for a 3D printed cockpit interior which I'm using to replace the very heavily gatored foam, and while I was at it, I printed a replacement tail cone too. I'm not sure if the ejection seat will be able to stay when I add the camera, so currently it's just taped in place.
1786492457386.png

I need to start figuring out how to vacuum form the canopy for the F-86D since making that as clear as I would like seems likely to end up being a major challenge of this design. One advantage of the F-86 canopy is that the front panel is already perfectly flat, so I won't even need to vacuum form it, I will be able to just cut it out and install it in the frame.
1786493372007.png
1786493397643.png
 

telnar1236

Master member
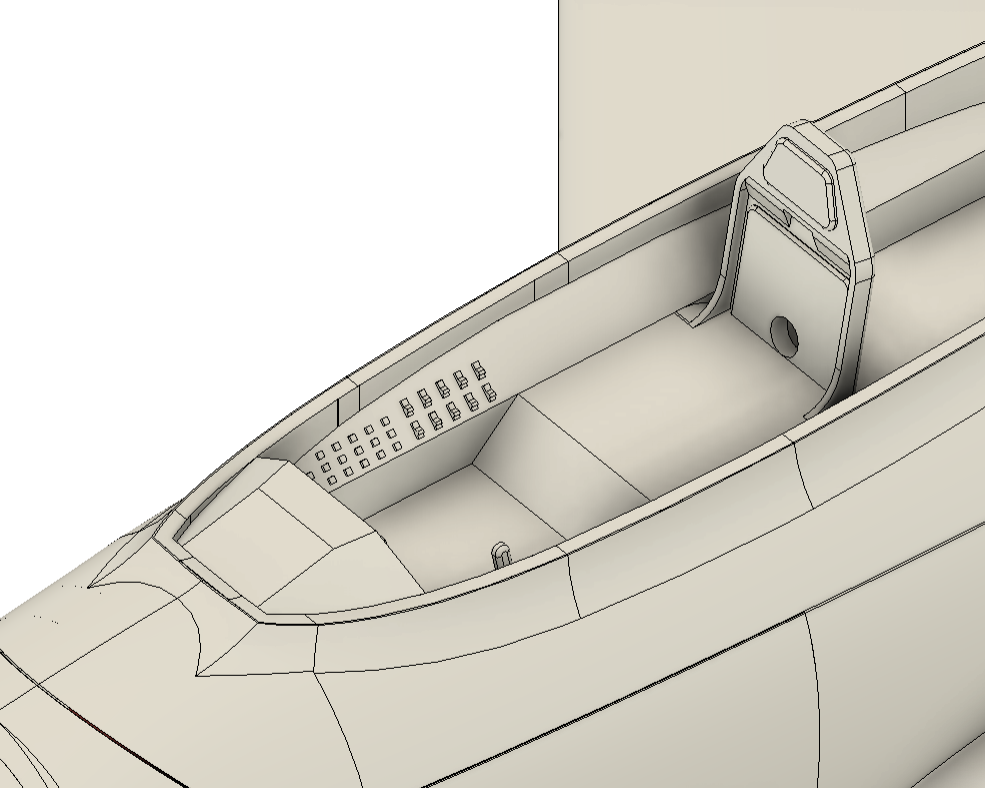
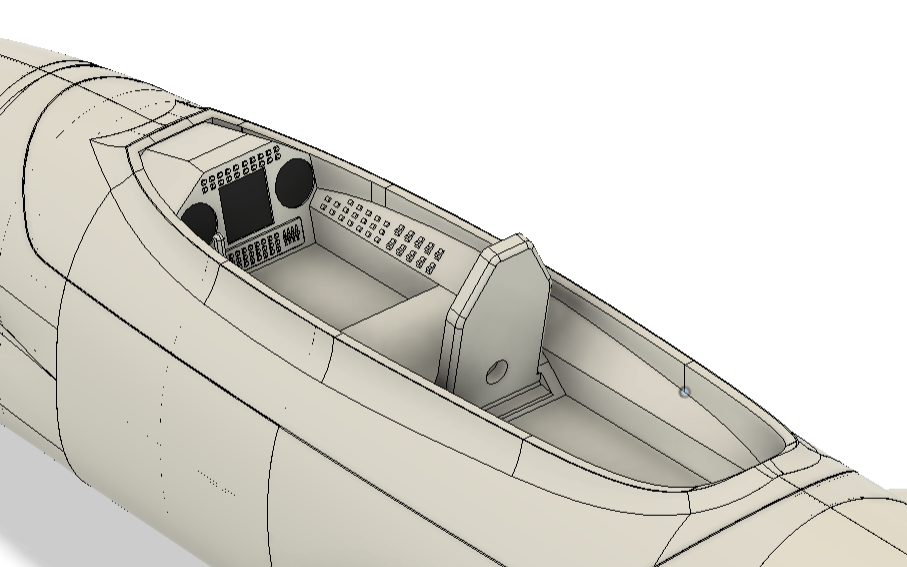
Spent a while modeling the cockpit for the F-86D yesterday. It's not very scale since it's designed for me to use for FPV instead of for a pilot to use it to intercept bombers so the requirements are a bit different but I did still include a bunch of fake switches and buttons because I think they look cool. The screens are currently designed to use a removable 3D printed backing in case I want to remove them to put in LED screens with flight data down the road.
1786655373880.png
1786655454489.png

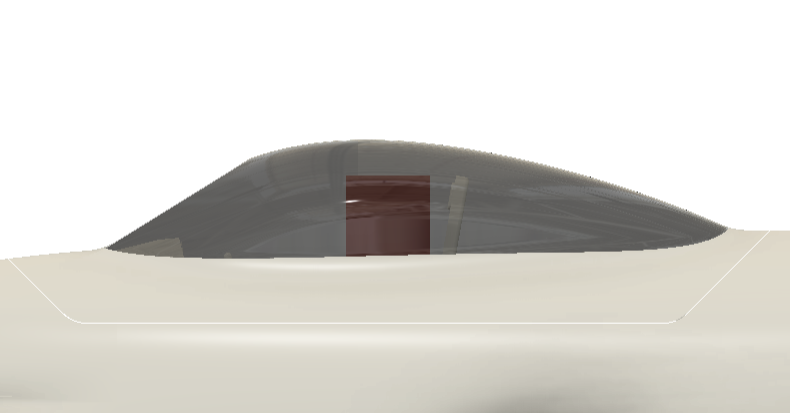
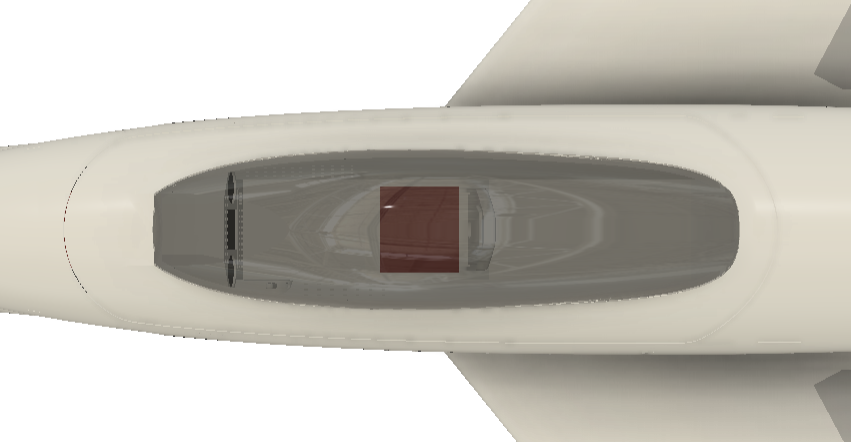
Unusually for me, the canopy will be one of the first parts I build since it's the whole purpose of this plane in many ways and a lot of the rest of the plane will be shaped around it.
1786655650207.png
1786655674063.png

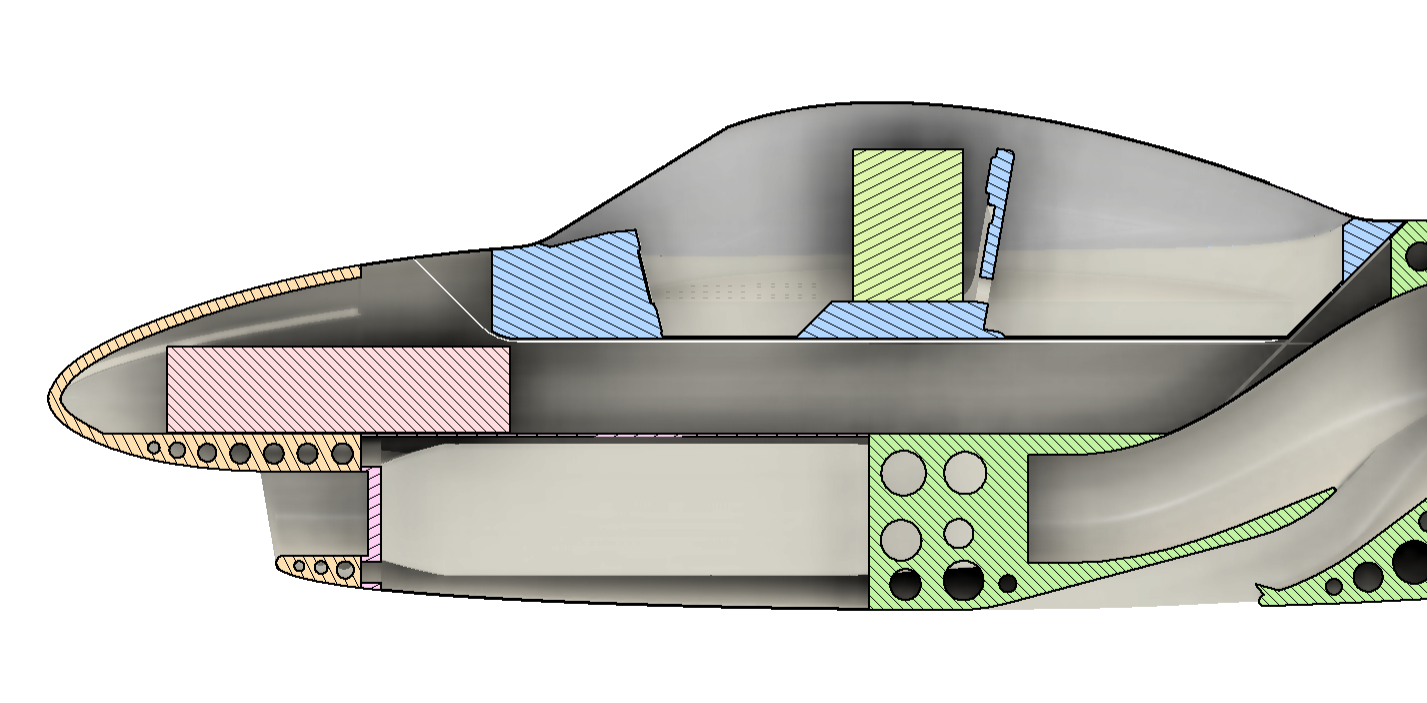
The big cockpit gives me plenty of space to put the gimbal and the slightly non-scale canopy outline should give me space to put the VTX and possibly a flight controller behind the seat. And there's also still plenty of space for batteries in the fuselage still - the F-86D really does have a ton of internal volume for its size.
1786655811150.png
 

telnar1236

Master member
Today was not a good day of flying - I brought four planes and 3 of them crashed. This included my Mirage 2000 with the FPV setup, but at least I'm glad I tried to fly everything in it before building my Sabre Dog since there were a lot of lessons that I was only going to learn from actually trying to integrate everything.
1786926387115.png
1786926420445.png


The good:
  1. The polishing technique I used on the canopy was great. I used polishing compound for cars and then added a ceramic coat and the canopy was crystal clear - you could barely even tell it was there. I won't be making any changes to process for the final plane.
  2. Ease of setting up the gimbal. I used the FMS Syncpilot system and it was very easy to get working. It also felt a lot more natural than I expected in use.
  3. The 3D printed cockpit turned out looking amazing as did the 3D printed nozzle - if you happen to have the plane and are interested, I got the files from here
  4. During the time I did get to fly it, the plane was actually quite controllable despite being the very twitchy Mirage 2000.
  5. When the plane crashed some very friendly dogs came over and wanted to help me pick up the pieces
The bad:
  1. The camera could only rotate 90 degrees each way in yaw and less than that in pitch with the default Syncpilot setup. From this experience I know that I want as much of the full range of motion as possible since I would love to be able to look over my shoulder and see the wing.
  2. It would feel even more natural if the head tracking had roll too
  3. The canopy was too small, as expected, on the Mirage 2000. It meant the camera bumped into the canopy on some rotations.

The crash causing:
  1. The camera lost signal in flight. The first time I was able to get my goggles off quickly and come around and land but the second time I crashed. Possibly due to the antenna orientation or due to:
  2. The VTX overheated quite quickly. Since I'm trying to fit everything inside a jet, I probably need a fan for active cooling and a heat sink.
Another thing that would help avoid a crash would be to set up auto level on a gyro or flight controller so I can switch into it if I have an issue like this and need it. The plane is repairable but I doubt I'll use it for FPV again since it really isn't the best suited to it.
 

telnar1236

Master member
Sorry to hear you crashed, it was a sweet plane.
To a certain degree that's why I put it together - to crash a plane I cared less - I knew something unpredictable would go wrong with my first attempt and this let me find some problems so hopefully the next attempt can be more successful. Hadn't flown the Mirage in a long time, and once I fix it, it will probably go back in my closet for another year till I have something else dumb to try with it - not a bad plane but it's twitchy and at this point everything it can do, one of my 3D printed designs can do better

Thought I clicked post on this on Monday
 

telnar1236

Master member
First couple parts for the F-86D - I was originally planning on printing the canopy first, but as I've been working on it, some of the other parts have needed to be designed pretty much entirely so I could figure out clearances, so I figured I'd add the finishing touches and print them.
1787176468720.png

Just using my normal gray Polylite ABS this time around since it's still the material I'm most comfortable designing for.