WiredForStereo
New member
Hi there,
I've done a couple searches looking for exactly what I need, but I'm only finding tertiary snippets of information. This might be one of those fun challenges that can help a few people who want to try out the Dragonfly configuration and get deeper into the control board.
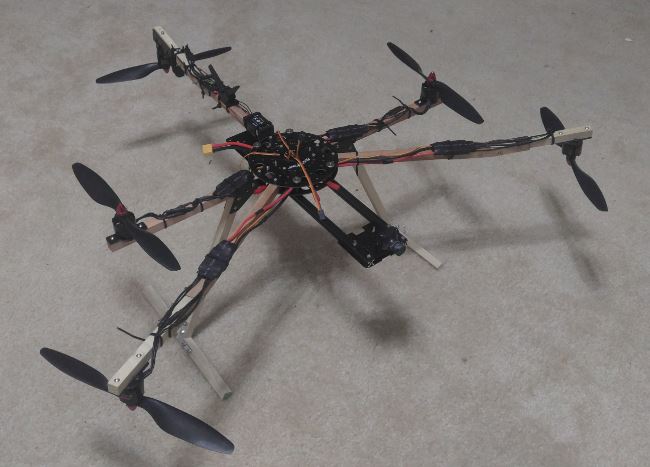
I'm doing a modified Dragonfly. The stock Dragonfly has five ten inch booms. I'm using angled boom ends which extend the three standard tricopter booms an extra 5.9". The center two motors are remaining on stock ten inch booms and without angled props (for now).
While putting this together, assuming I was going to use the stock y-connectors, I realized that they are a big bunch of mess to fit into the limited space. Then I realized that the Naze23 (rev6) board I bought for this project has six outputs. Why not just do a custom mix and forget the y-connectors?
Further thinking revealed that there are problems with the y-connector layout because while the front two motors contribute to pitch, the center two don't, and if they are wyed together, they could cause less than intuitive reactions to hard up or down stick. Also, since mine are of different boom lengths, a custom mix would further help to produce the correct reactions to control inputs, while still giving me the lift to fly my gimbal.
I found the following code for a tricopter:
mixer CUSTOMTRI
mmix reset
mmix 0 1.000 0.000 1.333 0.000
mmix 1 1.000 -1.000 -0.667 0.000
mmix 2 1.000 1.000 -0.667 0.000
smix reset
smix 0 5 2 100 0 0 100 0
profile 0
smix reverse 5 2 r
profile 1
smix reverse 5 2 r
profile 2
smix reverse 5 2 r
That makes all sorts of sense, but I've also found some info hinting at the idea that when in servo mode, two of the outputs are set to servo. On a Dragonfly, I need only one servo output and five motor outputs. Is this an actual hangup or have I just not found the right info?
I know the contributions of the different motors to throttle, roll, pitch, and yaw, but I don't know how to put it all into the final package.
In this configuration, what would be the motor numbering scheme?
Thanks for your time, and I appreciate any assistance you can give me.