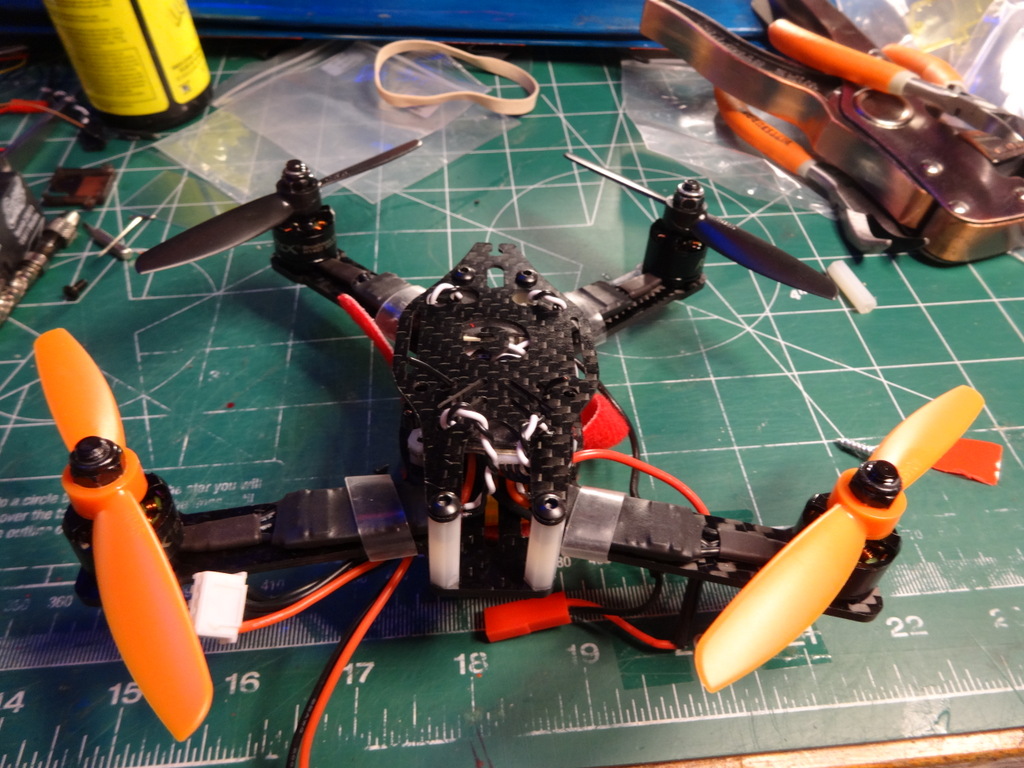
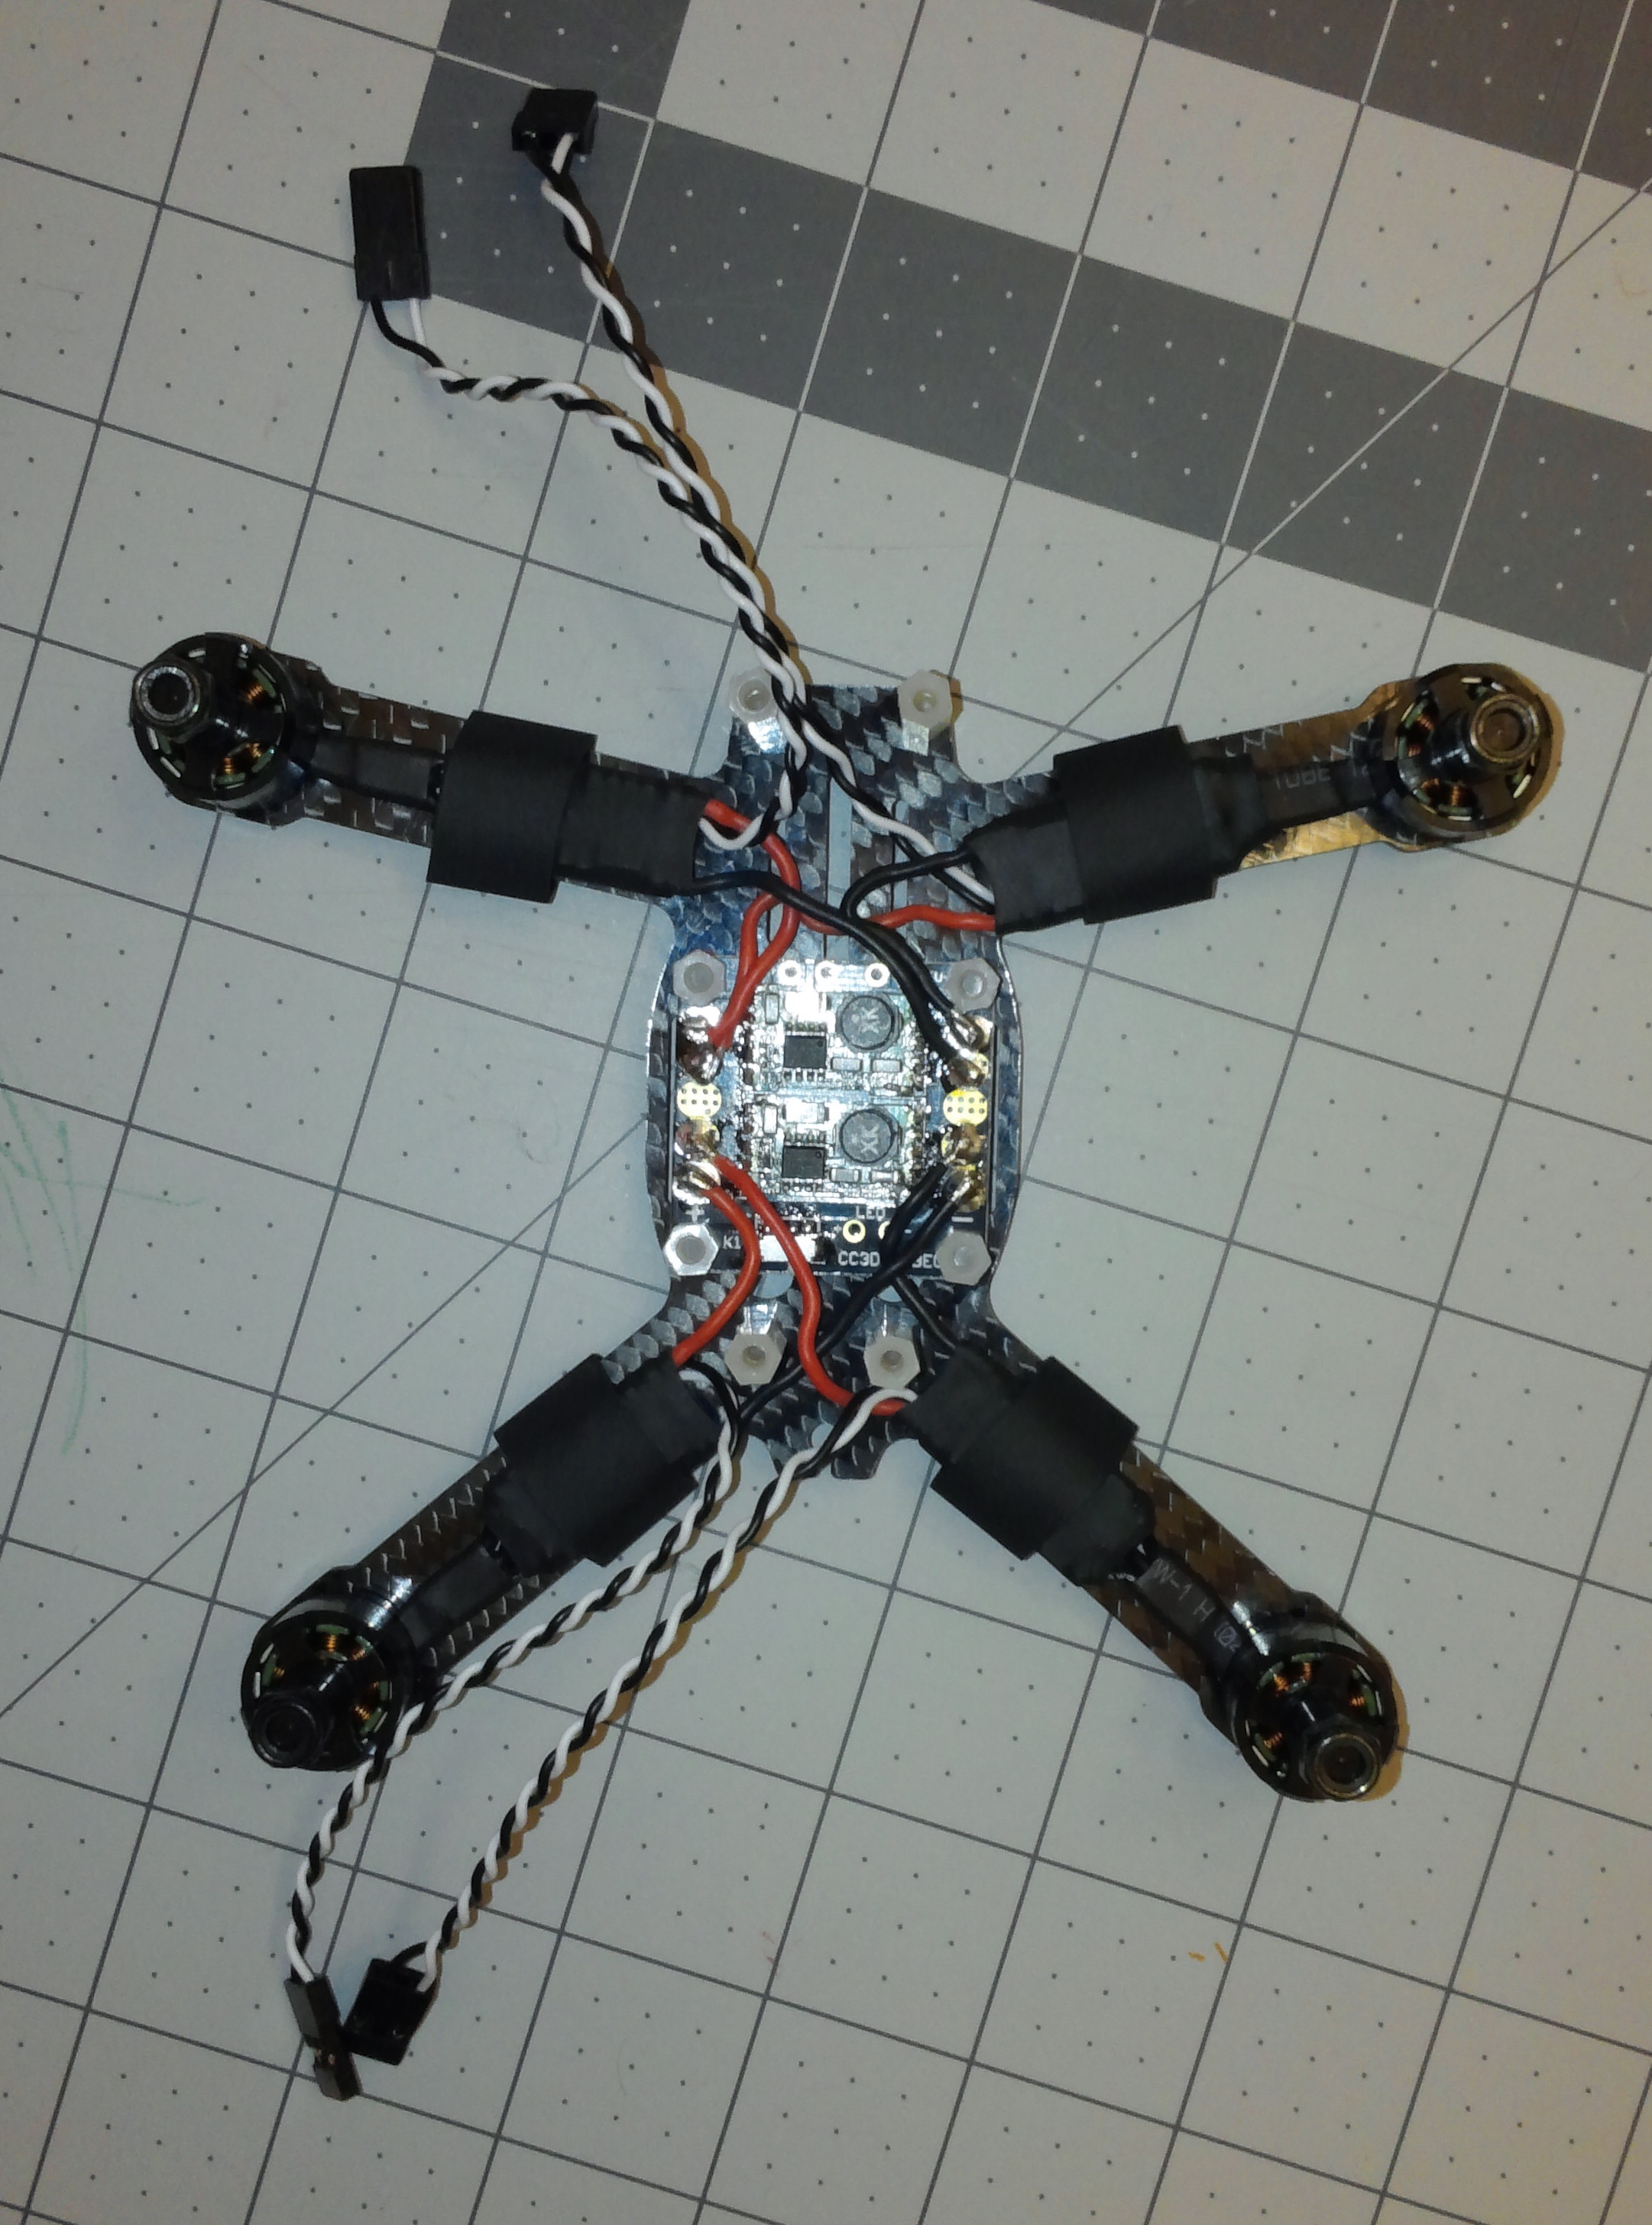
Under 250, Under 250, Under 250!!!

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Last we left off, the RX and Naze are mounted . . . and the harness was built.

Speaking of Cthulhu . . .


Disaster struck once more, and it's a multi-tentacled doosy!


a slight bump in just the wrong way . . .
DSC02965.jpg

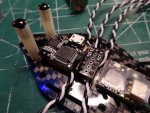
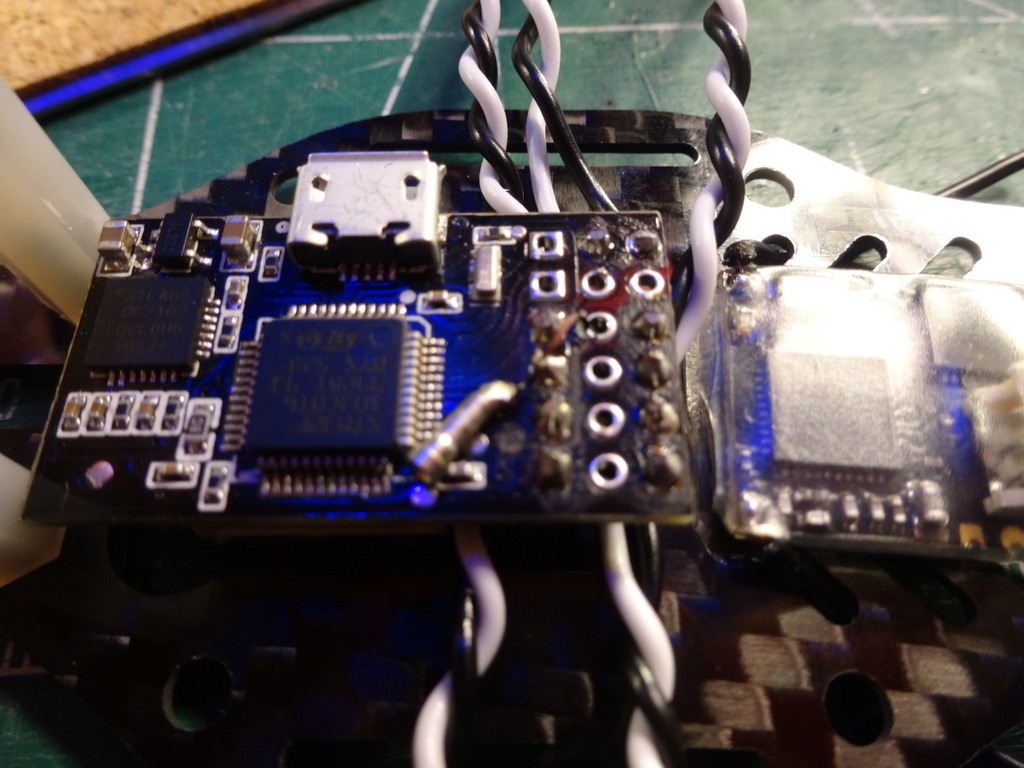
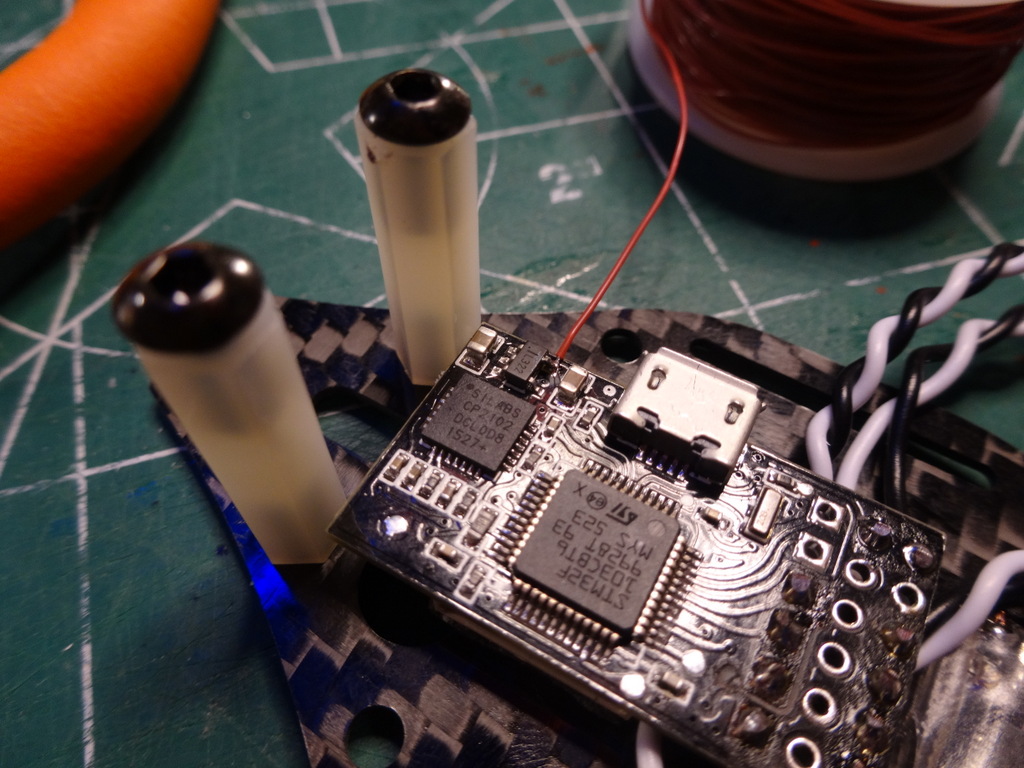
. . . and the pin lifted the pad right off the board :eek:

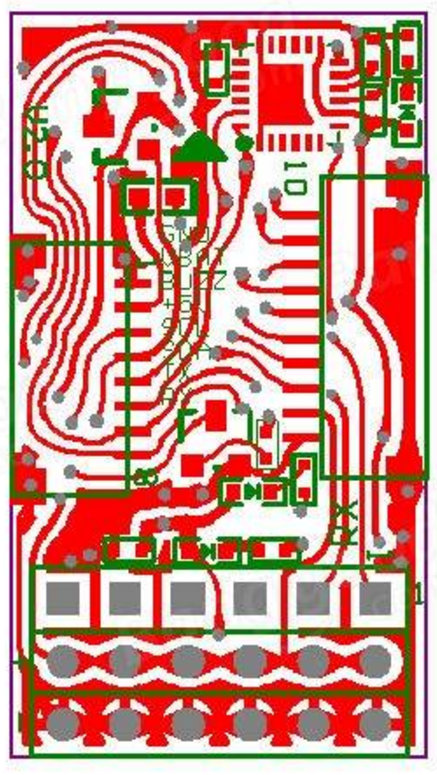
Ok, this is bad, but recoverable. Spent the next evening researching the board . . . even found a schematic of one side:
Fullscreen capture 2152016 93746 PM.jpg

long story short . . . wow. this board is sloppy. traces are all woppy-jaw, and looking at the vias connected to the other side, there are multiple paths through the traces for the same thing. even found that the pad next to the +3v pad wasn't the boot-loader, it's the programming clock. the bootloader pin is on the far edge of the board :confused:

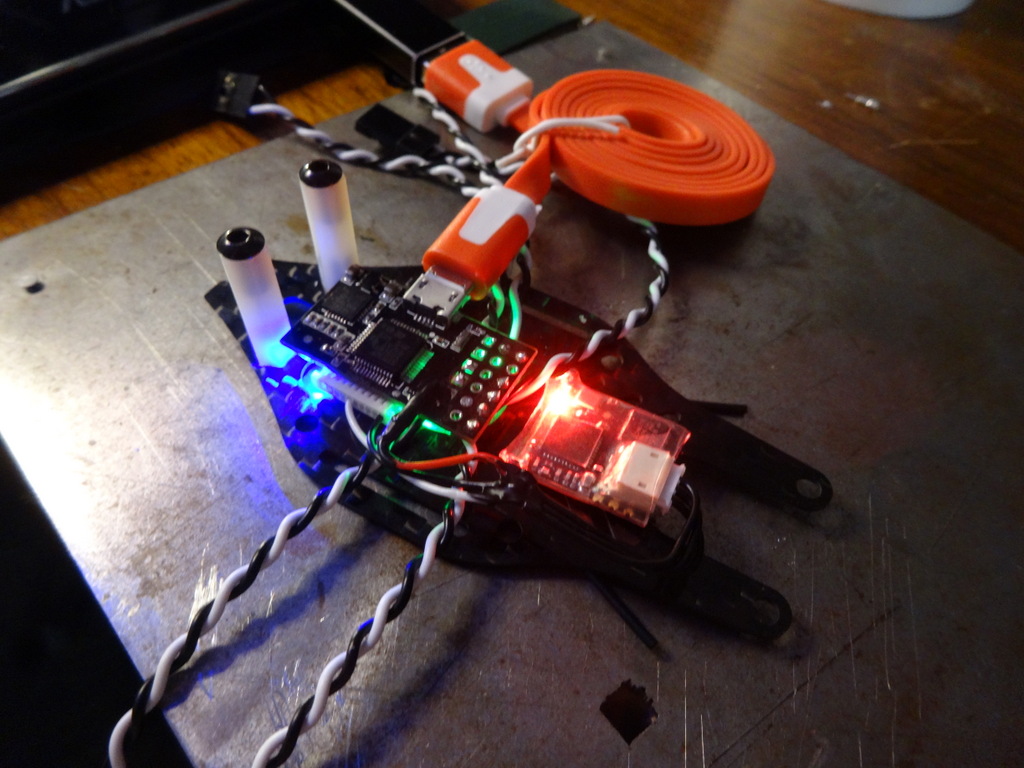
. . . a quick power up and found EVERYTHING STILL WORKS!!!! Thank God for little blessings -- this guy's sloppiness has paid off. the only thing I lost was this pad, so let's pull out some tools to fix this.
DSC02966.jpg

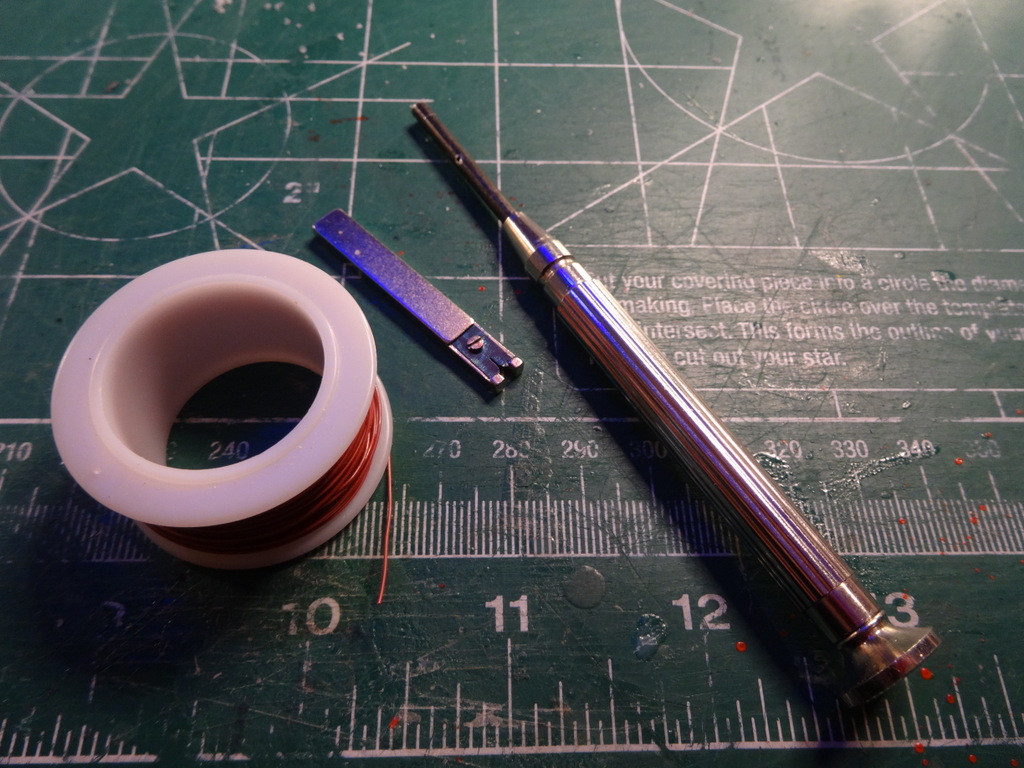
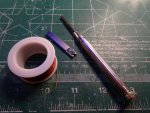
Tada!!! I pull out my trusty wire-wrap tool, and it's sidekick (who lives in the handle) the 30AWG wire stripper. pull out a spool of red (keeping with the power color), and time to strip an end:
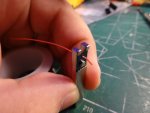
DSC02967.jpg

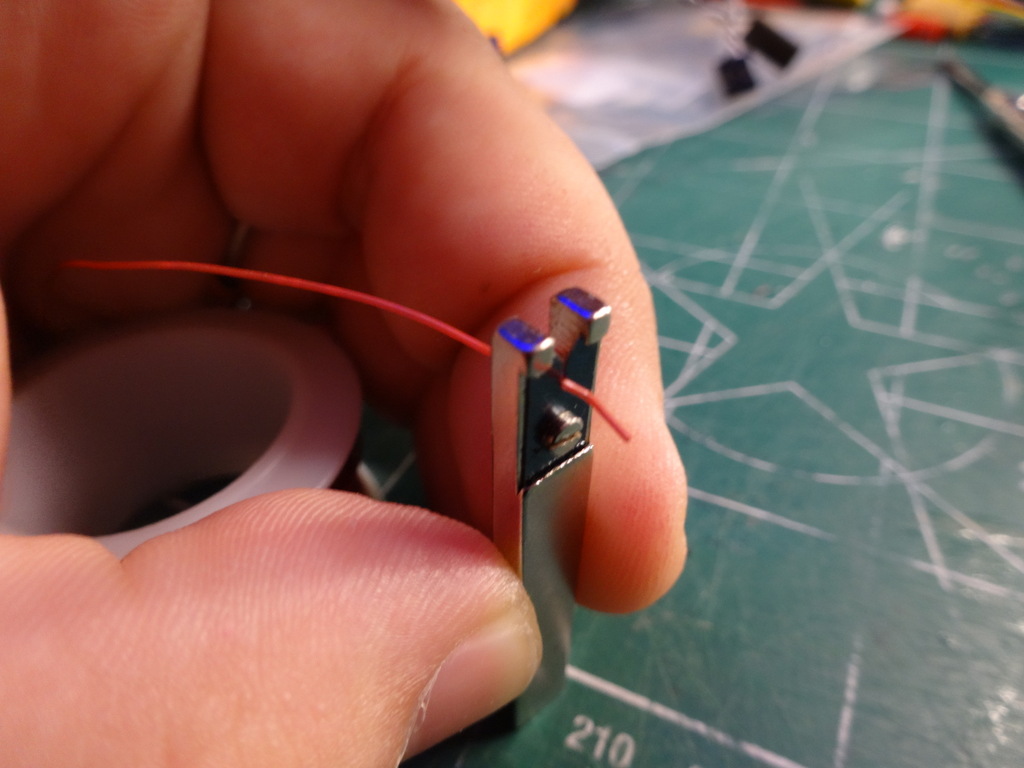
seat the wire in the stripper and pull . . .
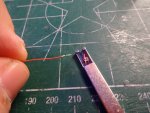
DSC02968.jpg

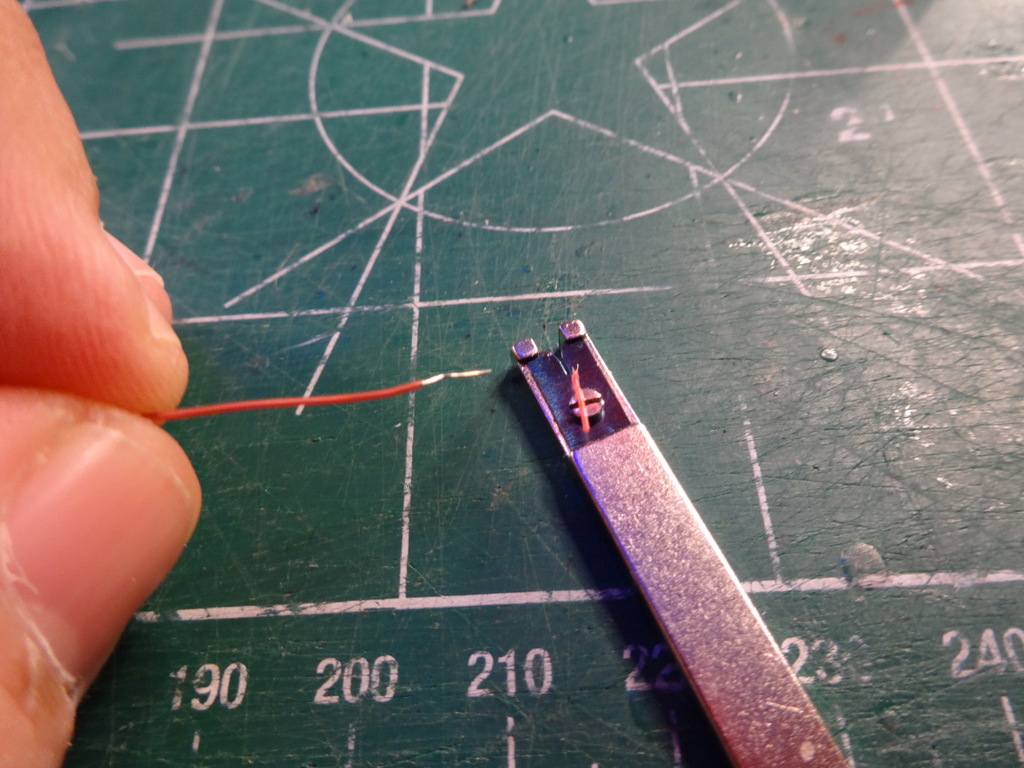
and you have a nearly-hair-thin wire ready to solder directly to the regulator output . . . now where is that thing hiding?
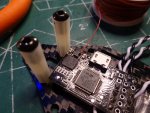
DSC02970.jpg

right! up in that top right corner. tack it in place . . .
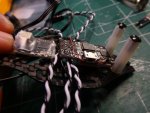
DSC02971.jpg

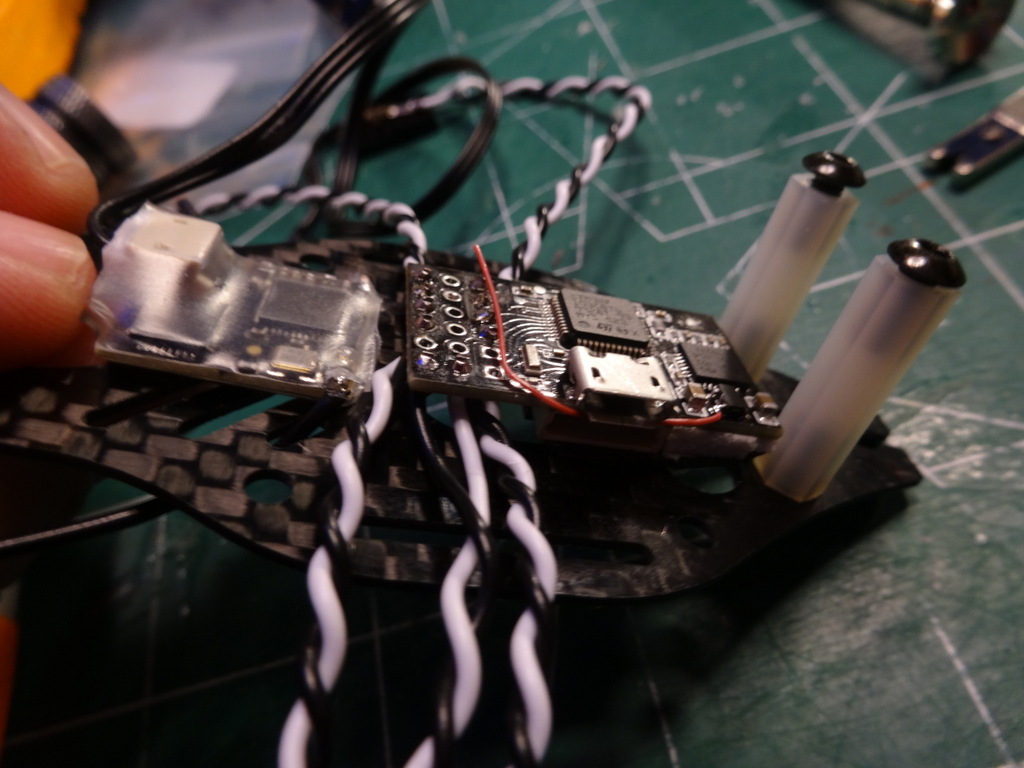
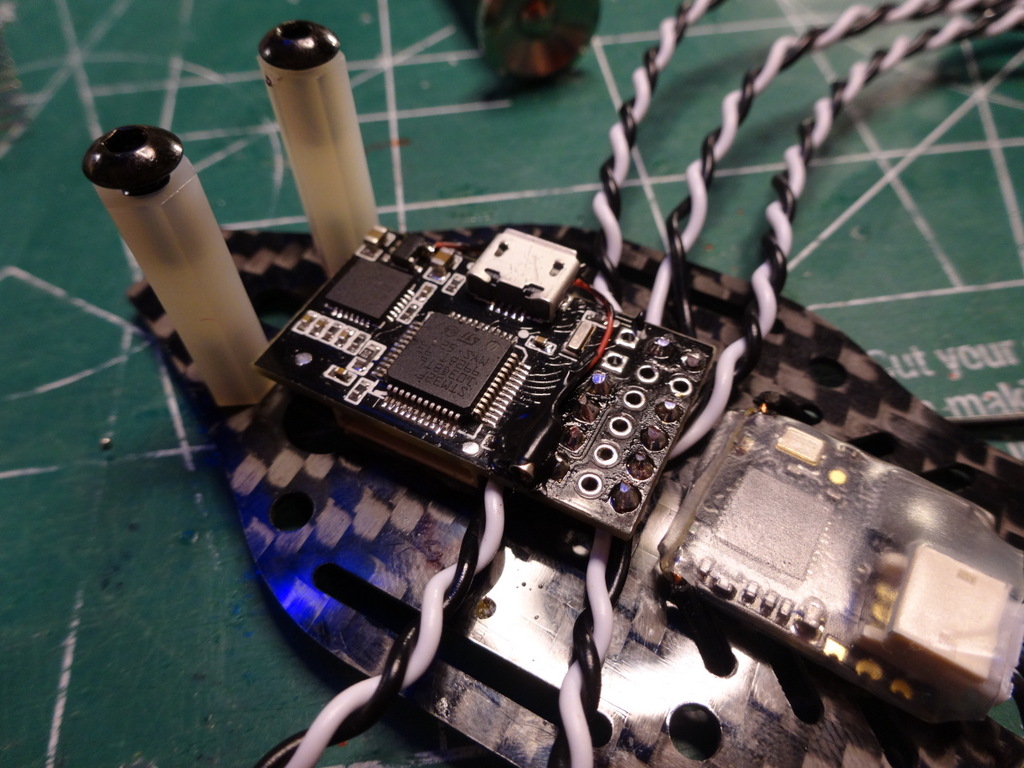
route it around along the board edge

DSC02972.jpg

and add the connector back on and GLUE IT DOWN (like I should have done in the first place!)
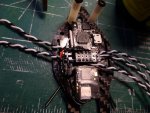
DSC02977.jpg

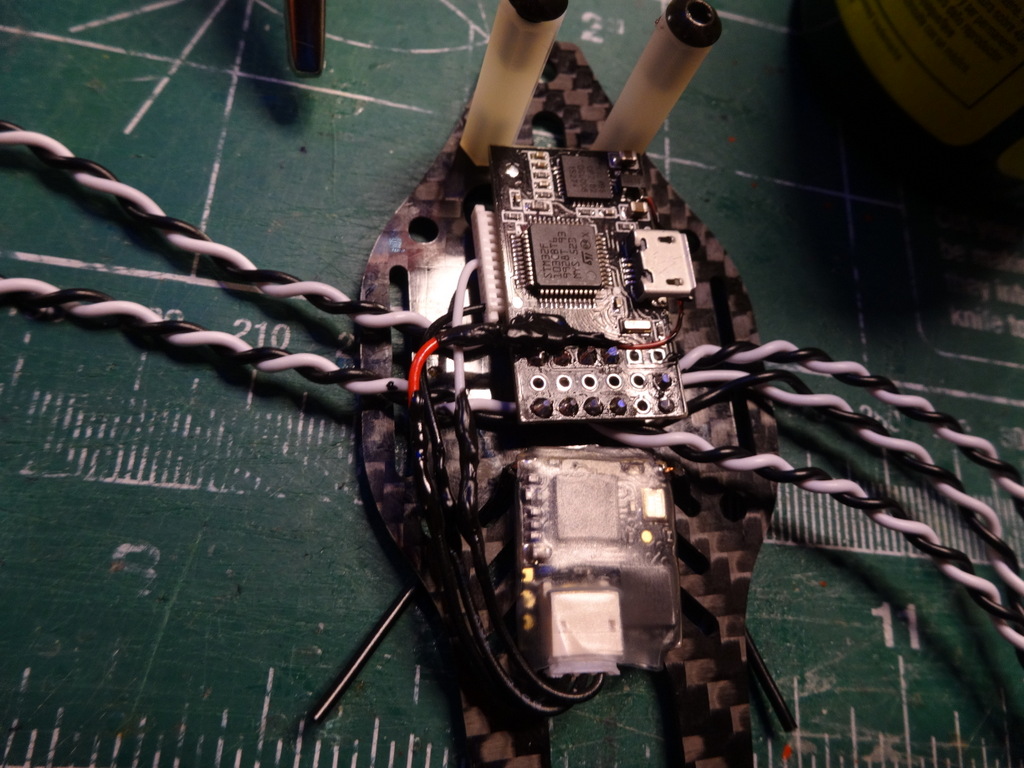
Plug the wire harness back in and we'er back in business! cover the exposed connections with liquid electricians tape (should I have added an extra 50g or so for as much as I'm using ?!?)

and we're done! time for some testing!

Did I hear time to test?!?

the RX and Naze board should connect up, so let's plug it in, do the basic config steps and bind the RX.

So the connection is good, first REFLASH to the latest ROM. you'll need at least 1.11 to get the pass-through we'll play with in the next session, and if you don't do it now, the next few steps will have to be repeated :p

Just to prove it can be done . . .

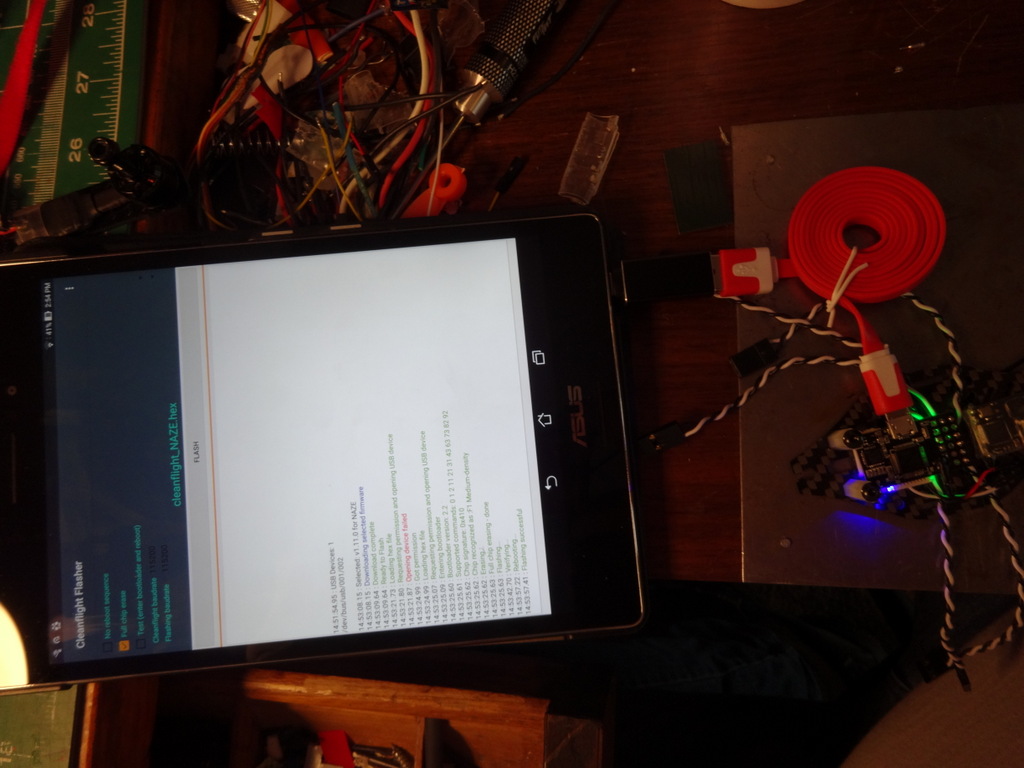
DSC02988.jpg

I pulled out the Android "cleanflight flasher" and loaded 1.11.

Ok, back from the flash . . .

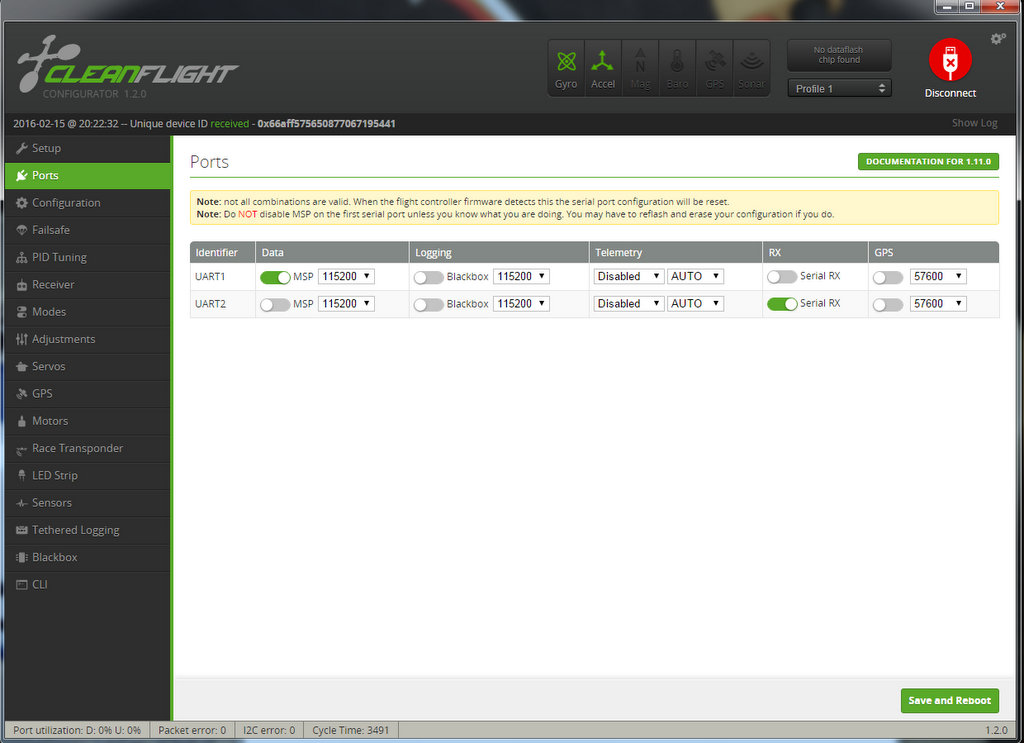
we need to setup UART2 as the RX port (NOT UART1!!!! Change this and the USB port will stop working!!!! DON'T DO IT!!!)
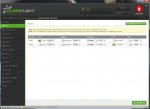
Fullscreen capture 2152016 82252 PM.jpg

Done!

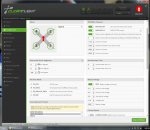
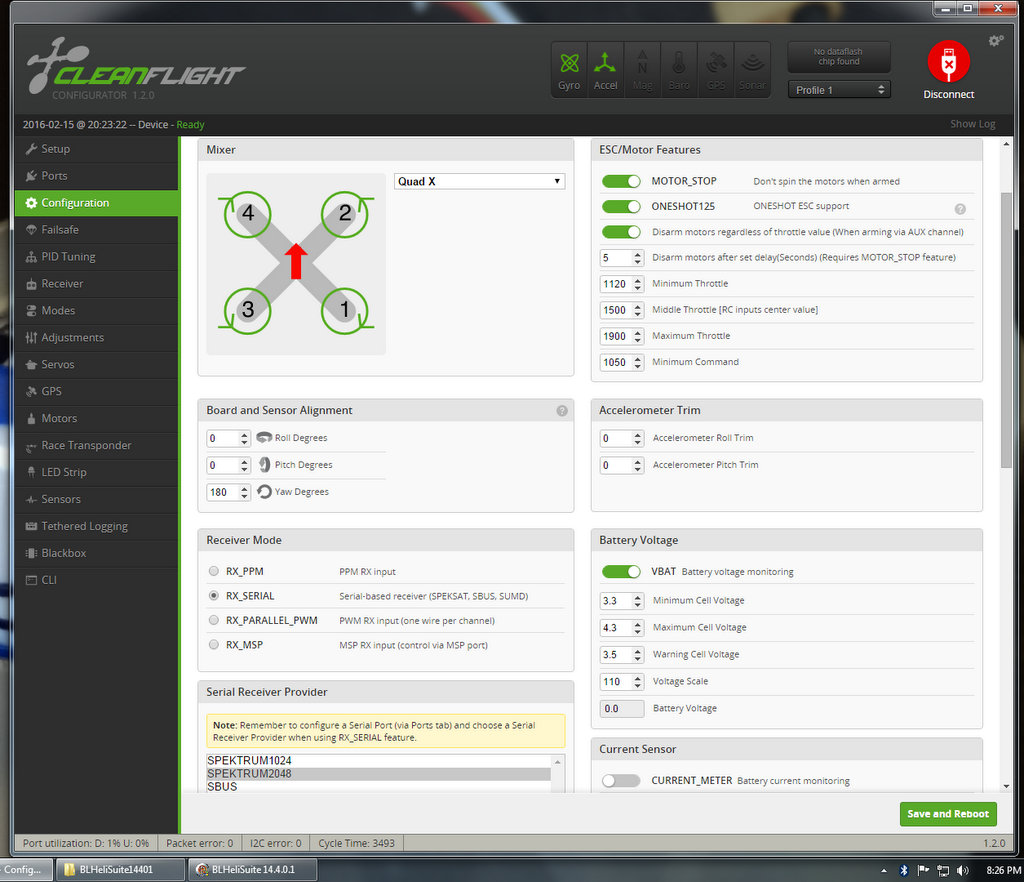
Next, hit the config screen:

Fullscreen capture 2152016 82616 PM.jpg

odd difference between this and the Android App "EZ-GUI Ground Station" -- I couldn't get it to pick anything other than Spektrum 1024 :p seems the command interface for this variable changed from a number to only accepting the name . . . so the android app is broken until it can be patched. the fix?

Go in CLI and type: "set serialrx_provider=SPEK2048" followed by "save" to lock in the change (if you want something other than Spektrum 2048, sorry, you gotta look that name up yourself)

In a bind . . .

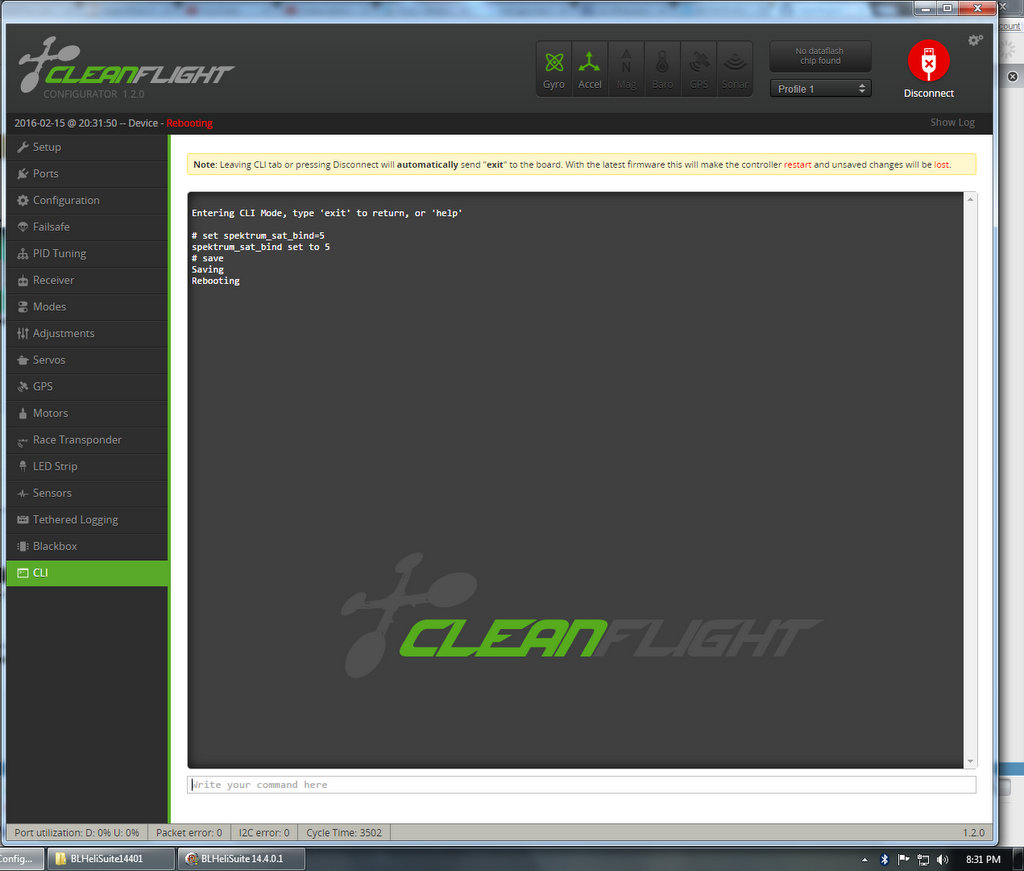
and finally, on to the CLI to trigger the bind process on the sat.
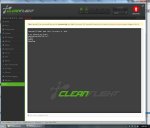
Fullscreen capture 2152016 83151 PM.jpg

Run the commands above:

set spektrum_sat_bind=#
save

The number matches the type of bind, for instance, 5 = "DSM2, 2048, 11ms". look here for the number you need:

https://github.com/cleanflight/cleanflight/blob/master/docs/Spektrum%20bind.md

so now that that's done . . . how do you trigger it?!? the board needs to cold-boot. power it down completely (unplug it), and power back up. in the reboot, the sat should start blinking and now's the time to bind the radio.
DSC02990.jpg

Bada-bing-bada-boom! your RX is bound, and the RX screen should start responding!!!!

So what's all this I hear about power?!?

The next session we wire in the ESCs . . . and play with flashing down the wire, the way it should be . . . and the testing get's really interesting
 
Last edited:

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
LOL. If it's already broke, I can't make it worse ;)

Freeing thought, and gotten me into more trouble in electronics than it's gotten me out of . . . but along the way you learn a few tricks you can use to dig your way back out.
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Last we left off, the control deck is functioning and responding to the transmitter . . but . .

What good is brains if there's no brawn to back it up?!?

Time to wire up the ESC leads . . . surprisingly, we've done all most all of the work.

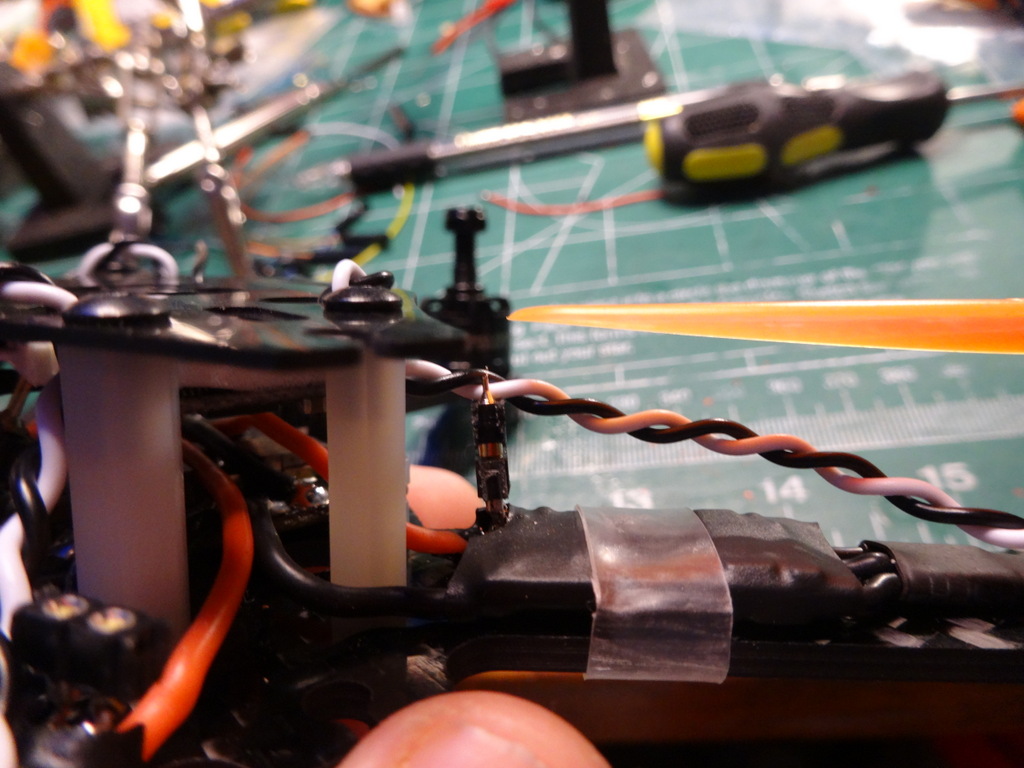
I went ahead and mounted the control deck ran the wires along the top (I also routed through the frame to hold them in place . . . shoulda taken a pic of that :( ), then line the wire up with their corresponding plug:

DSC02991.jpg

snip, strip, tin, solder, repeat, repeat, repeat. Do the same for the 5v harness and you've got a wired airframe!

Now before we go off and wreck her in an insta-flip on maiden . . . let's look into the ESC flashing.

Fastest Flash in the west!!!

Ready?

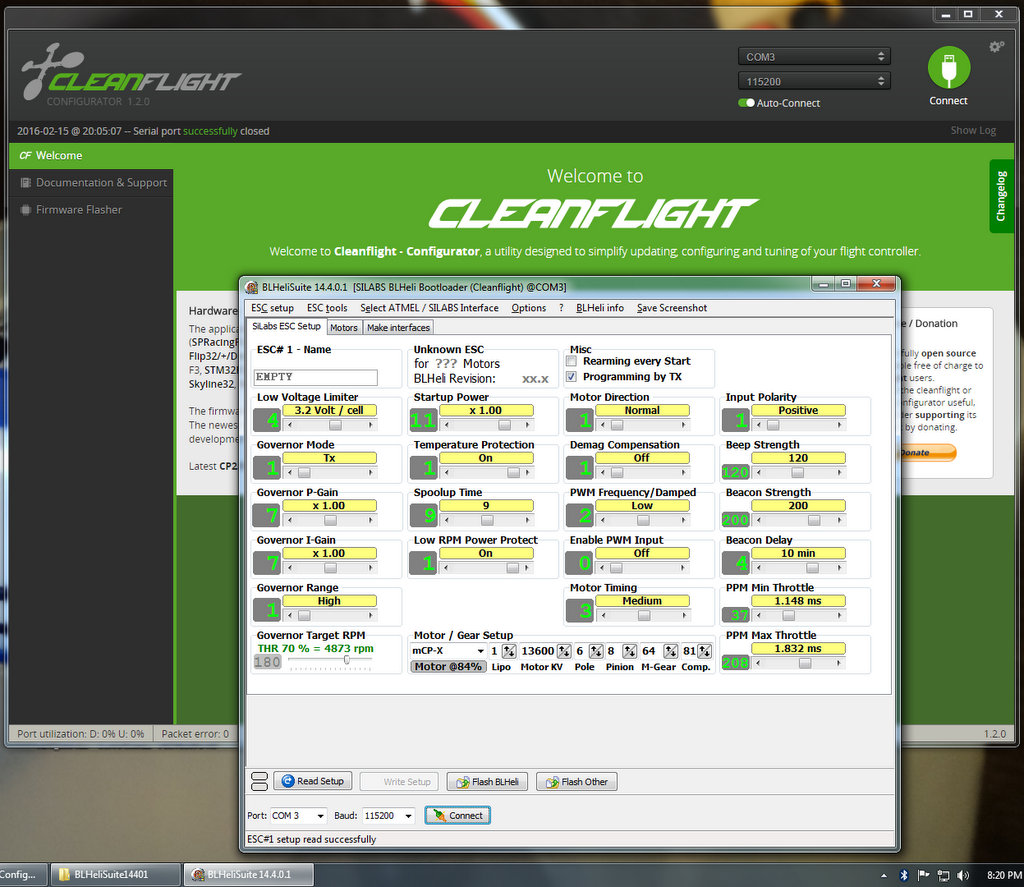
- hook up the control board tot he PC to connect to cleanflight as before . . . but don't hit connect. if it auto connects, disconnect.

- download and open the latest BLHeli suite (14.4.0.1 as of time of writing) and open it

Fullscreen capture 2152016 82038 PM.jpg

- copy the connection settings (com port and baud, if they're not already right)

- power the ESCs

- click connect.

- click read.

Fullscreen capture 2152016 82055 PM.jpg

In like flint.

It's completely transparent -- either connect with cleanflight to mod settings on the board, or connect with BLHeliSuite to reflash/mod settings on the ESCs.

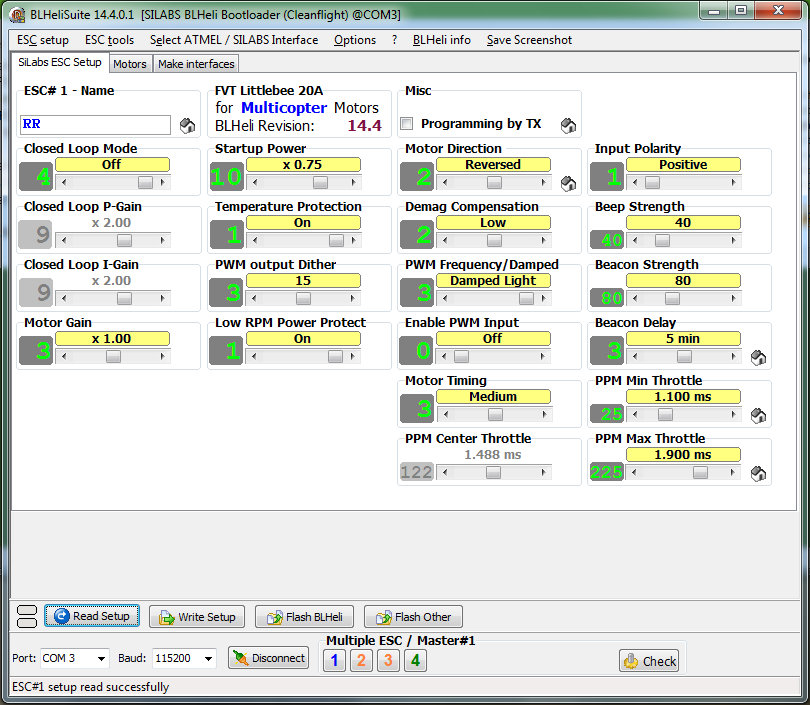
First things first, if the ESC isn't up to the latest, hit the "Flash BLHeli button and it'll check, find the right ROM and download the update. Approve and it will take you through the process of flashing one-by-one. after each it'll ask if you want to copy settings, tell it no if you haven't already setup the ESCs the way you like it. this way you start with the factory default for the latest version.

Next, go in and make some changes:

Fullscreen capture 2152016 82107 PM.jpg

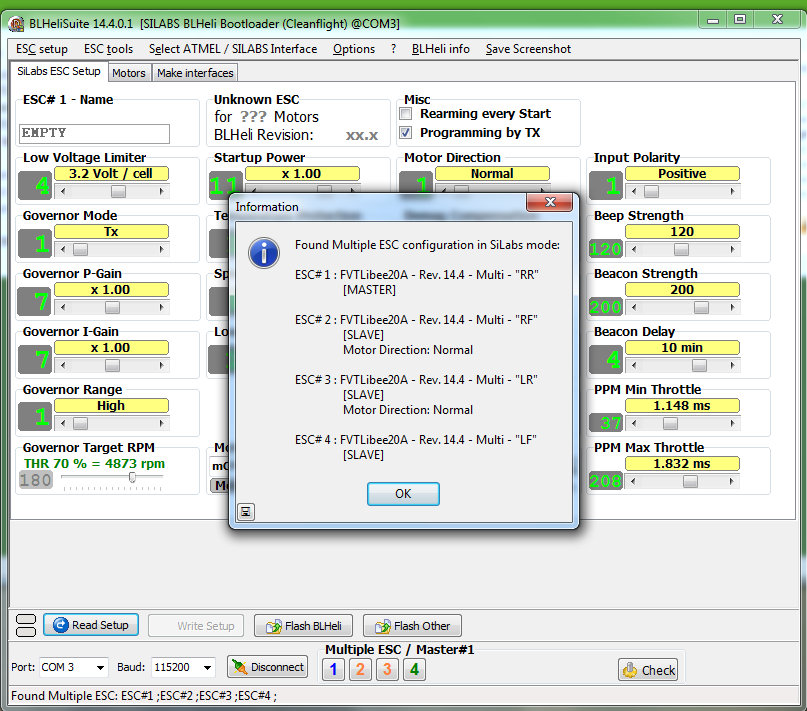
To select among the ESCs, click the 1-4 buttons at the bottom. The lowest numbered ESC will always show. some settings are synced among all selected ESCs, some are allowed to differ (like name and motor direction).

For my sanity, I set and write a name equating to the boom position --RR = right rear, LF = Left front, and so on.

I'll also clear the Programming by TX box, so the Naze can't mess this up by accident -- I don't expect it to, but no sense leaving a feature on that can come back to bite you.

Next I'll set the beacon to trigger at 5 min (personal taste) set the minthrottle to 1100ms, and the max to 1900. In the radio I generally set the throws to just above and just below these settings, and min/max throttle on the Naze is set to 1050 and 1900, so these numbers should be good (min on the naze should always be lower with margin, and max should be right about the same spot). You can write all these settings at once (if 1-4 are all selected) or one at a time, using the copy/paste function on the bottom right. Most everything else can be adjusted in further tuning the ESC to the motor, so we may revist this, but for now, we're good. Time for the last step.

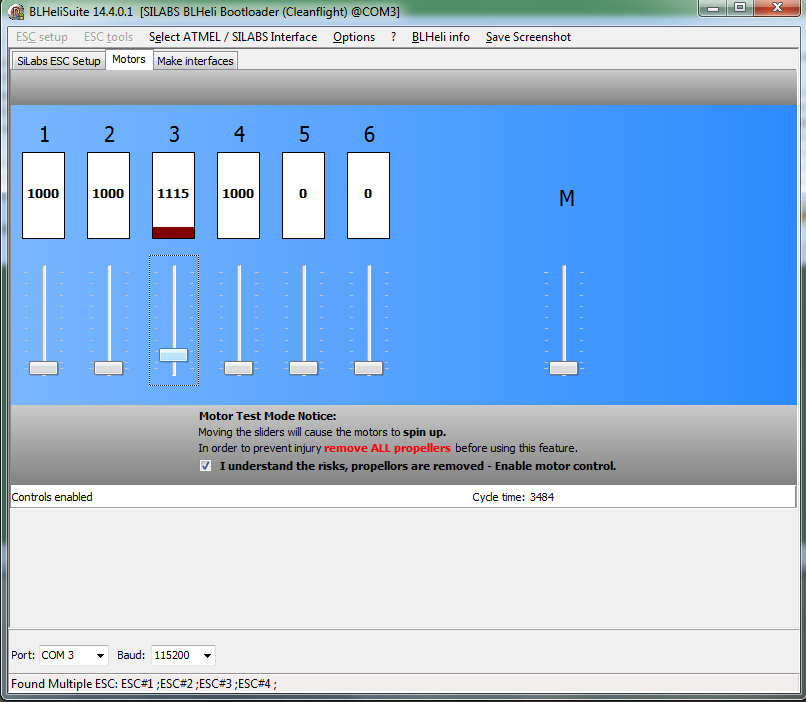
Set the motor direction -- start with #1 . . . and switch over to the motors tab:

Fullscreen capture 2152016 82146 PM.jpg

Dang, that's handy. Don't even have to leave the BLHeliSuite to test the ESCs. spin#1 and see if it's going the right way. #2? #3? #4? Go back to the setup tab and more, hit read, then set the motor direction to reverse for the motors spinning the wrong way and write. go back and test and when they all spin the right way . . .

. . .you're ready for props!!!

Tight Means Really Tight!!!!

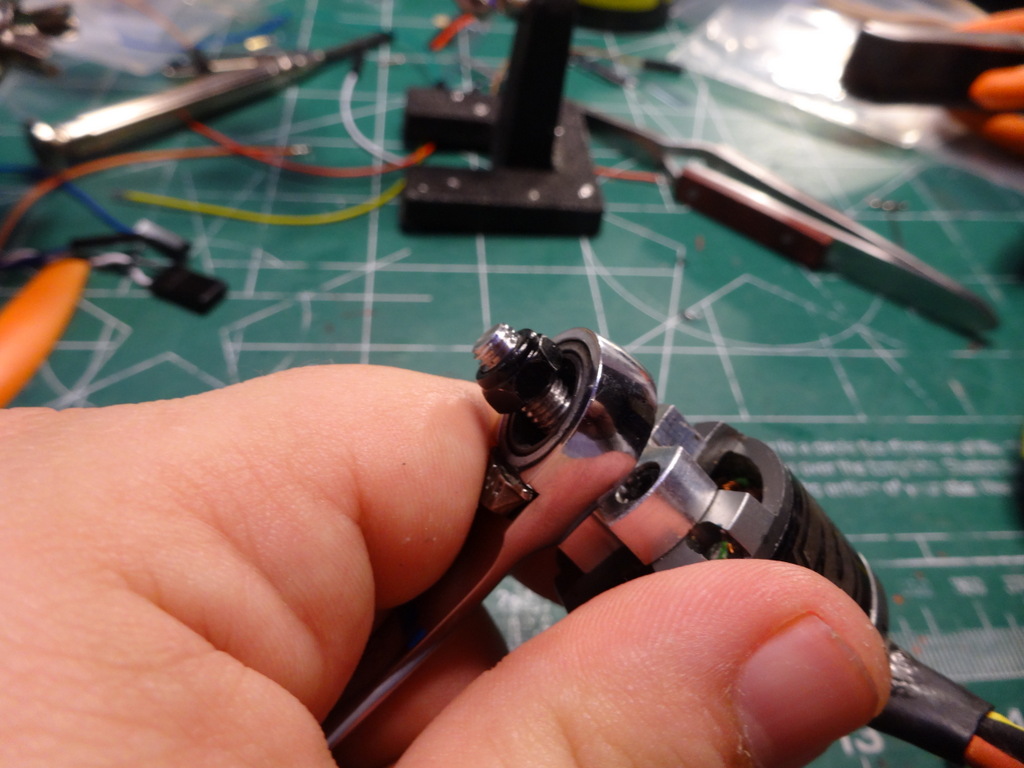
One of the headaches with the shrinking motor is how to get the nuts tight and stay tight. a common solution is mixing left and right handed threads . . . .but if you ever loos a left-handed nut, you're in BAD shape. I prefer nylocks, but they can be stiff.

DSC02992.jpg

VERY stiff.

Pre-cutting the nylon with a larger motor helps loosen them a bit, but there's a BIG difference between tightening a nut on a 28mm bell and a 14mm bell. there's not much metal there on the 140x motor bell, so you don't want to squeeze down for fear of warping the bell . . .

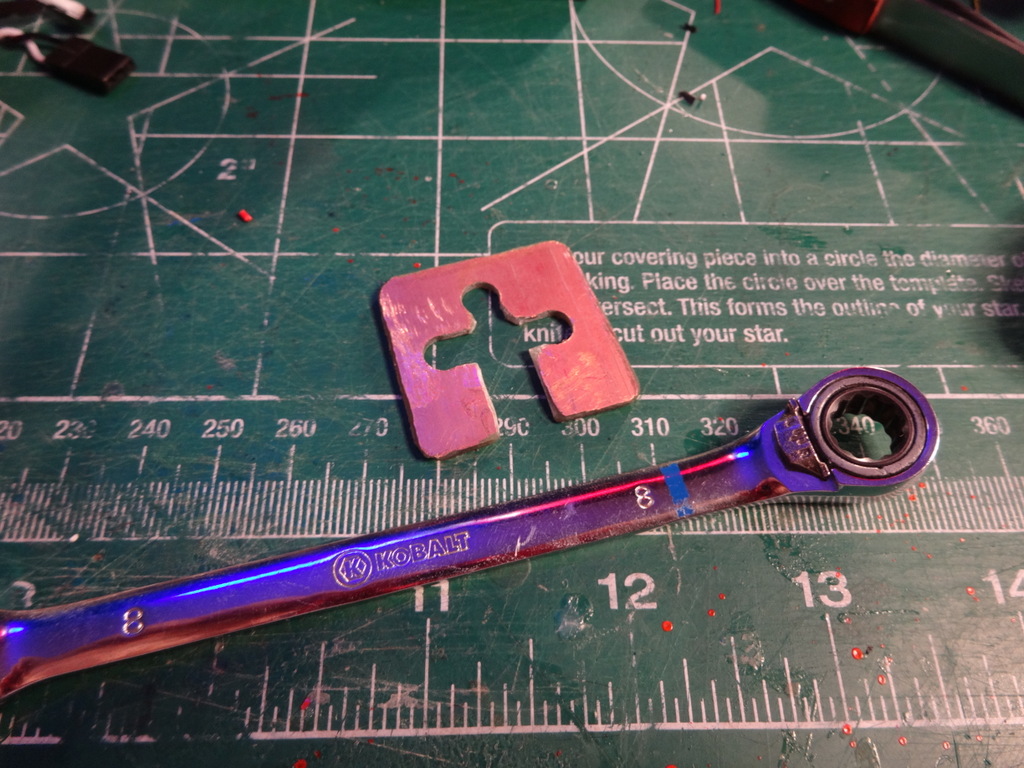
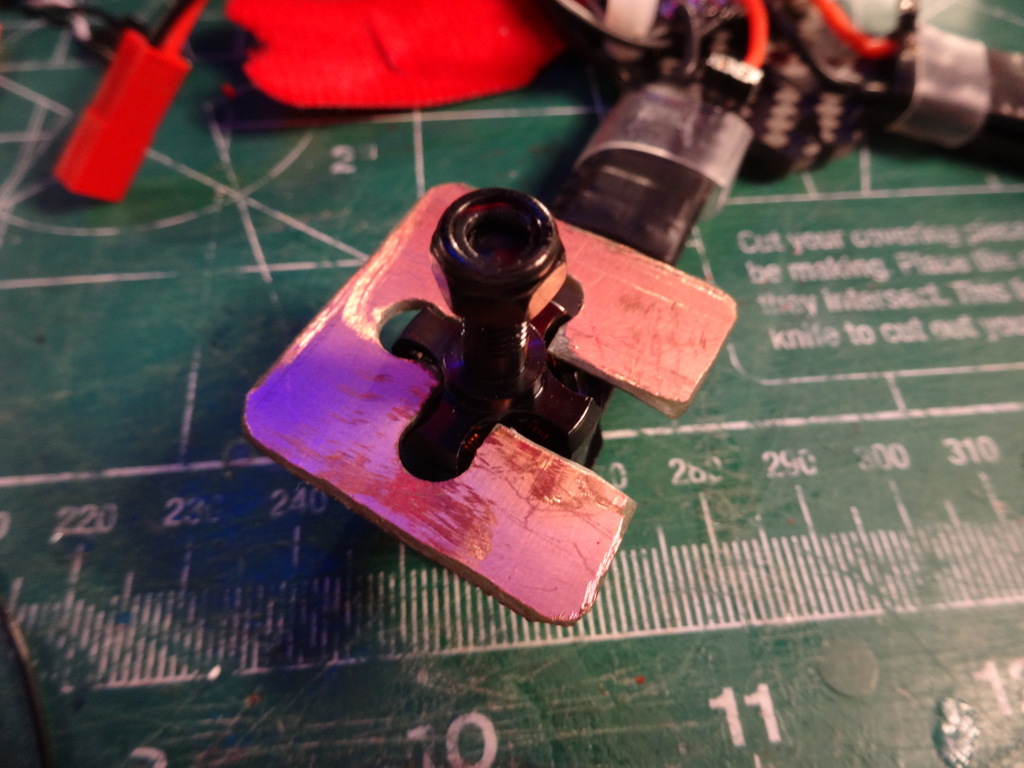
Enter the E-Motor Wrench:

DSC02993.jpg

That's the copper thing, not the silver ratcheting combo wrench.

While I came up with this myself, I don't expect it hasn't been obvious to others. Simply put it fits over the motor veins with a notch on one side big enough to fit around the spacer between the prop and the veins.

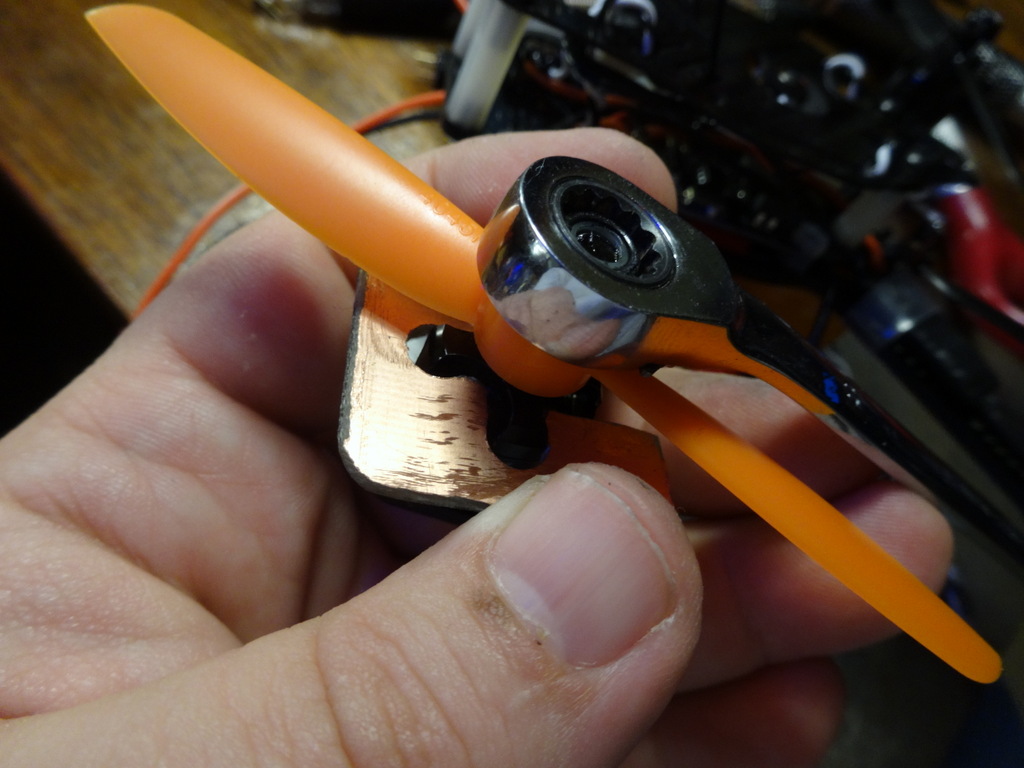
DSC02994.jpg

Slip on the prop, hold the motor still with the the E-Motor wrench and tighten the nut down putting stress on the parts designed to take it:

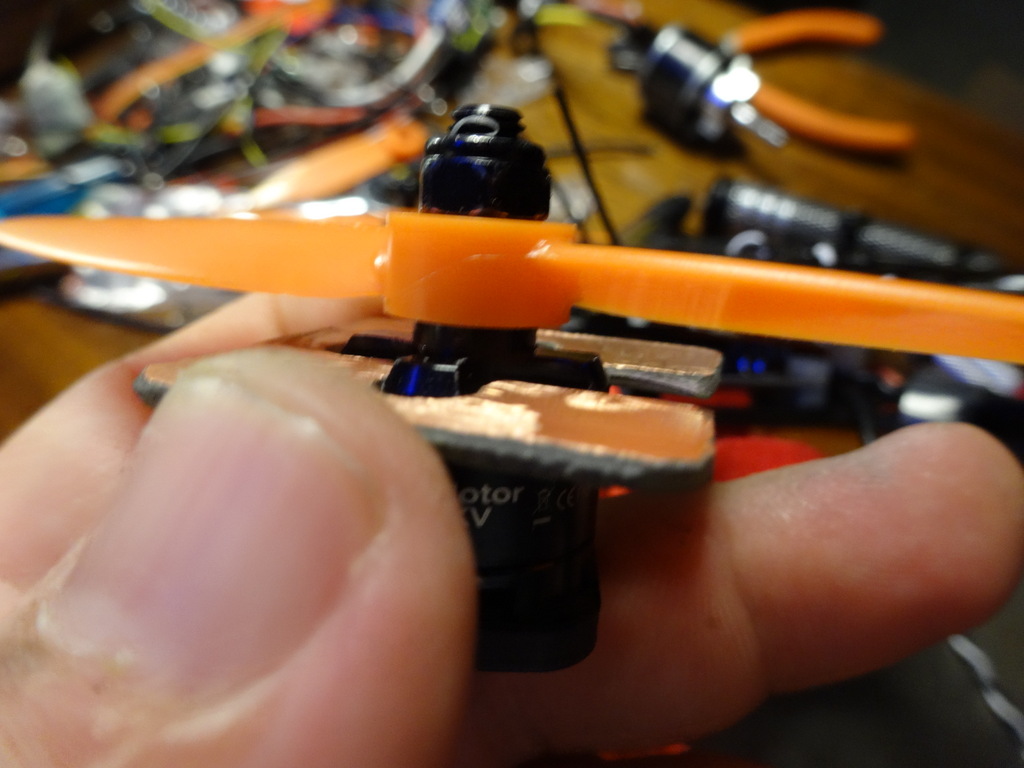
DSC02995.jpg

When it's all tight, the E-motor wrench is just thin enough to slip out -- lift it up over the veins . . .

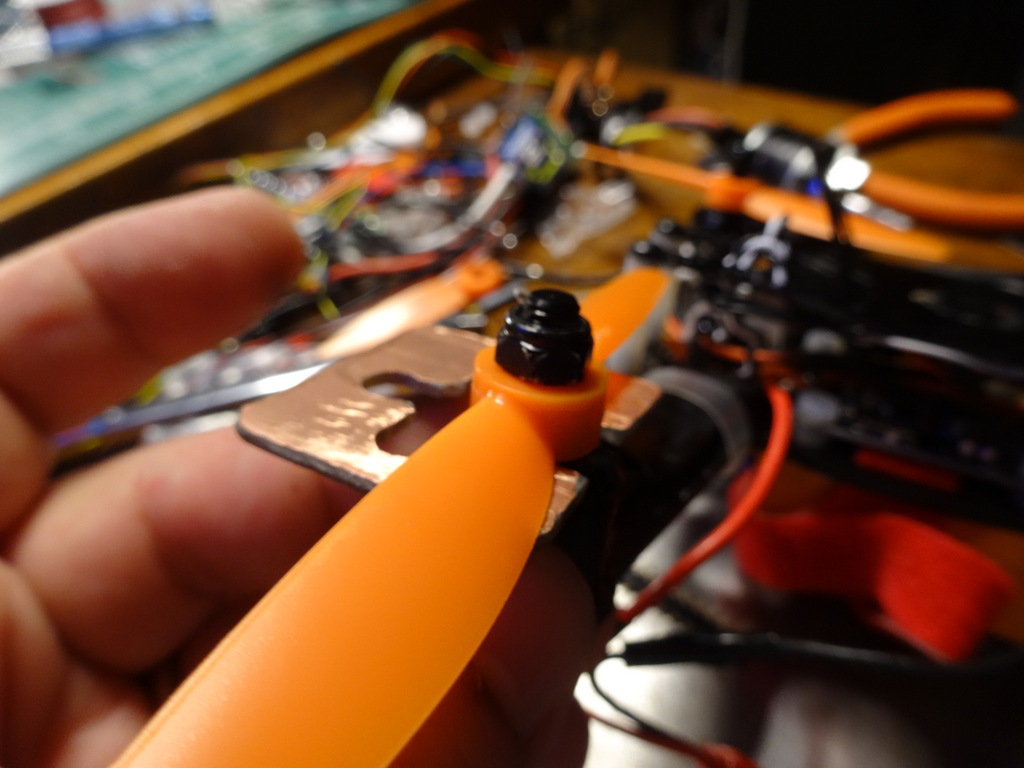
DSC02996.jpg

And slide it out in the larger notch:

DSC02998.jpg

Repeat, Repeat, Repeat . . . and we have a functional quad!!!!

DSC02999.jpg

Did I hear someone say TEST?!?

Time for a maiden :D


YAYYYYY!!!!

Wait, I thought this was an FPV quad?!?

yup. setting up the camera comes next . . .
 
Last edited:

makattack

Winter is coming
Moderator
Mentor
Nice! I hope new multirotor builders take a look at your thread. Though this is more of a super advanced build, they could learn a lot from your detailed documentation of your steps; in particular your maiden test.
 

jhitesma

Some guy in the desert
Mentor
Like the motor wrench. I was doing something similar on my 1806 DYS motors but basically just using a screw driver to brace against...worked great. Until I slipped and gouged the windings :mad: The DIY wrench looks a lot safer :D
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Thanks, All. It's always fun putting it to the test for the first time :black_eyed:

For those who might have not understood what was going on in the vid, every time the props stopped abruptly was because I cut the throttle -- Damped light halts everything freakishly fast. Get enough throttle it can lean (sitting on the battery as opposed to skids makes this a bit more interesting) and gently lean/spin it all the directions, one at a time. The goal is to see if I have enough control to lean and spin in each commanded direction. If I can't do that, no sense moving on until the issue is fixed.

Being out of tune (and I suspect the I-gain was a bit to high in the gyro loops), and not fully free of the ground, the error in the control loops can cause the ESCs to slowly rev up out of control. In the air, it's not a problem -- the error tends to bleed out as it flies. Sliding along on the ground, though the feedback loops aren't as nice and it might cause a flip.

Moral of the story, if it acts weird, throttle gets cut. If it sometimes acts weird, it might be because it's still connected to the ground. If it ALWAYS acts weird (or instantly flips on it's own) go back and check your connections to see everything is in the right place, spinning and moving the right way

I'm also running ridiculously low on throttle, because the high thrust:weight ratio. That makes it just that much harder to control. We'll fix that in a bit.

The last few bursts I made before lifting off was to get back to a tail-in orientation. I have just enough room in the kitchen to test, I don't need to fight orientation at the same time ;) The liftoff was a lot slower than normal -- I generally spin up a touch then pop up a few feet, rather than skitter around a few inches off the ground before gently lifting out of the ground effect. I can blame touchy throttle . . . but mostly just sloppy piloting on an untried frame.

Jhitesma,

It's a nice solution -- not sure how well it works across multiple motors due to varying dimensions, but I was racking my brain trying to figure out how I could hold it by the veins safely without doing exactly what you describe. That and at 3200kv, if I scratch up the bell, the little of off-balance from that could make a VERY strong vibration.

Depending on how much clearance you have between the veins and the prop, you might even be able to 3D print something like it for a particular motor, but on these motors that clearance is 1/16". perfect for the copper-clad fiberglass I used (it's what I had on hand!) but might be a bit thin for a thermoplastic to handle. I have seen 3D-printed clamps with the DJI motor shape imprinted on the interior, so that might work in lieu of the flat plate. I've got a buddy who is CNC'ing a set of these to spec out of G-10 . . . when his shop gets back to a livable temperature. I'll post how those do when I get some in.
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Brutes indeed . . . Oh look, they're only twice the price as the 1407's and if they're like most other 1806's, only 40% heavier :p

Cost aside (after all, what's +$40 to a $250 budget), the extra 6g (x4) would have blown my weight budget. I've got wiggle room, but not 24g worth. If this project is to be mud in the FAA's eye, the 250g goal is a hard limit.

. . . and no specs to go with it? better and better. Meh. Thanks for the link, but I'll pass for now.
 

PsyBorg

Wake up! Time to fly!
Just got back to see progress on this. Seems you were a busy man while I was away. Congrats on the maiden and nice work on the board repairs. that thing is smaller then I pictured in my head. I think Id have to be soldering thru a microscope to even see them small pads.

Congrats again on a successful maiden. I cant wait to (try) n see it in flight outside once its tuned and stable.
 

AdamV

New member
I'm a little confused with 2 things:
1. How does the naze power the satellite. Will the board itself down-regulate the 5v input to 3.3v out for the satellite?
2. The mini naze says it only supports PPM rc input but also has UART pads for spektrum satellite? Clearly you are using a satellite on yours, i'm confused. (I feel like I'm confusing something stupid easy)
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
PB,

You'll be surprised what a simple magnifying lens and pre-tinned parts will let you get away with. I've assmebled raw boards on pads this size with nothing more ... But not much smaller. The grain-of-sand size resistors and caps that a professional pic-n-place machine can do are a marvel to me.

Adam,

You guessed right. The brains of every STM32 board I'm aware of do run off a 3v rail, and every board I've seen running the *flight ROMs has a tiny regulator onboard. On this board, the tiny black part in the top corner I tapped the red wire to (6th pic on post #41) is it. Plenty of headroom on that regulator to power the board and a Sat Rx. Wouldn't chance much more load, but this much should be safe...assuming I don't rip the easy-to-get-to pads off the board :p

So that covers where I find power for the Sat....how do I get the data? That would be from any available UART port, and to find where those come out, I wander over to the board section of the documentation:

http://https://github.com/cleanflight/cleanflight/tree/master/docs

Specifically for my board, since it's a naze clone:

http://https://github.com/cleanflight/cleanflight/blob/master/docs/Board%20-%20Naze32.md

Two things to keep in mind: As I mentioned earlier, UART1 is connected to the USB, so if you want to be able to flash and configure things , leave it alone. Also, "soft serial" steals processing power, so if you intend to tighten the loop time, best to not use them if you can get away with it. For this board, that leaves UART2, which uses RC4 and RC5 for RX and TX data lines. The Sat serial only needs the RX side to run, so RC4 it is ... Which is typically the RX input for the Rudder position. Ground is the third wire in that bundle, so pick any convenient ground (hey look, pin #1 on that connector is ground). Set the software in ports and confg tabs, and that will replace a dedicated Sat port on a board that "doesn't support" it...

...which really just means they didn't make it easy on you. The trick is knowing where to look for where things get routed in/out.


Haven't made a lot of progress this week :( been hunting power and noise issues in the FPV gear, and I need to lock in on something that works before I go much beyond mounting the camera. I've got a plan, but I need to test it...and an extra pair of regulators...one of which I burned out yesterday :p At this point I've got a workable-ish setup without the OSD, but just need a touch more clean power for it.


...but more on that later....
 

AdamV

New member
My parts came in today, and i'm off to building!
20160224_234527.jpg

I'm going to flash the Little Bee ESCs, then direct wire them to my motolabs Tornado F3 board. I never get to fly over grass, so i'm reluctant to mount the battery on the bottom - will likely put battery on top, but to get the VTX to fit, i'm gonna likely have to use higher standoffs 20 or 25mm (vs 15 that it comes with)
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Sounds like a plan!

you'll loose a little bit of fine tuning you can do on the ESCs (I haven't played with closed-loop on these guys to know if I can tighten it even more, or if it simply goes nuts) but just reflashing to the latest and turning on damped-light willget you most of what you need.


I got the camera setup and mount done last night, too late to write-up unfortunately. Probably be two separate posts . . . I'll try to carve out some time to get them up tonight.
 

offaxis

Member
Dan,

Could you put together a BOM for this build with links of where you purchased components? And put it on the first post so if others want to duplicate your build they can find everything easier?
 

AdamV

New member
I probably spent the better part of an hour last night just thinking about how i was gonna lay everything out on this tiny thing. Would be a lot easier just to mount battery underneath and free up the top plate.

I'm very eager to see how you mount that little camera - thats one thing I've not decided on yet - though i imagine there is a 3D printed solution available if i can't come up with one
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
Dan,

Could you put together a BoM for this build with links of where you purchased components? And put it on the first post so if others want to duplicate your build they can find everything easier?

Perhaps after I've sold these ;)

In all seriousness, that's a good suggestion. I am planning a post-project synopsis with BoM, but also shop stock, tools used . . . the things that tend to disappear into the noise that most people forget. As for the BoM . . . I'm not done yet. There's already a few recommended changes and added parts that first and second-pass hindsight have shown. I've touched on a few as I've gone through, and will hopefully hit them all before I'm done . . . then summarize.

I'm 3/4 the way through the build recap now -- Mostly install the FPV gear and tune it all up -- and this last 1/4 has been the most troublesome . . . and less than 2 weeks before SMS . . . um . . . yay?
 

Craftydan

Hostage Taker of Quads
Staff member
Moderator
Mentor
I probably spent the better part of an hour last night just thinking about how i was gonna lay everything out on this tiny thing. Would be a lot easier just to mount battery underneath and free up the top plate.

I'm very eager to see how you mount that little camera - thats one thing I've not decided on yet - though i imagine there is a 3D printed solution available if i can't come up with one

Oh just you wait. 3D printers ain't got nothin' on me ;)

That's the update after the next, which I might just post back-to-back. we'll see how late it gets tonight :cool: