LitterBug

Techno Nut
Moderator
Got it. Reverse servo on inav and then reverse direction in tx Outputs did the trick. It's looking good.
I have been burned by having a servo reversed before. With a gyro/flight controller, it is always important to make sure the servos react correctly to the plane movements before checking the sticks. If the gyro isn't happy, it will take the plane down faster than you could probably do it yourself.
 

toryander

Active member
I had my first flight controller fpv flight this morning. It was nerve wracking. I tried to use auto launch. I don't think it worked (because I don't know what I'm doing). I got it in the air, anyway, and switched to Angle. At this point my plane lost power and wouldn't respond to my commands. I'm not entirely sure of the sequence of events, next. I think I hit switches with nothing regaining control of throttle and attitude. I finally settled on RTH as I watched my plane become a dot in the sky heading for the mountains. "I just lost my plane," I said to my wife. Then, RTH must have kicked in because the plane turned and started back toward me (I hoped that's what it was doing). It did come back. I tried Angle and Horizon, but I had no control with those (it would sort of respond to sticks, but not really). Thank Heavens I had Manual programmed in because it flew great without stabilization. I flew around and enjoyed the views and then aborted one landing when I could see the barbs of the barbed wired zooming in, came around and this time landed smoothly enough. Whew! Can anyone enlighten me on what's going on with my stabilized flight modes? The gyros worked perfectly on the ground when I did the checks. I did forget to bring the flaps up for much of the flight, but would that have ruined stabilization? Or was it a combo of being in Loiter at the same time as Angle? Manual allowed for both very nicely. I got some nice video I will put up, eventually. Flying with flight controllers is so much more complicated than I ever imagined. But I did it (kind of). :)
 

LitterBug

Techno Nut
Moderator
Having a 6 position flight mode switch helps me avoid potentially incompatabile flight mode combinations. Having manual mode has saved me on more than one occasion. I have always flown my Stratosurfers on Ardupilot, so I can't say much about how INAV would feel on it. I have flown INAV on Nano Goblins, Nano Skyhunters, and a ZOHD Drift. I prefer the way Ardupilot handles RTH, but it does work on INAV. INAV RTH always seems to freak me out at first because it seems like it is going away from me too long before making the turn back. I have a pair of FCs that won't run ardupilot that will be going in an AR wing, and FPV foamboard something.
 

Jo's squadron

Elite member
After all that learning and work I took my Stratosurfer out today for a run. The idea was to fly with the FC and Camera on, but without using the goggles, so that I could study the video and learn how to "see" with this configuration. Then I would go out again and fly with goggles. This is how it went:
OUCH!
 

toryander

Active member
I finally arrived. I had my first, complete digital fpv flight with the Stratosurfer this morning. I launched it with Autolaunch (oh, wow, that was the best--no death dip or torque roll). I buzzed my neighborhood and did a victory roll (and loop . . . and inverted), and then landed with a 25 foot slide across the hard, dry earth. I've already experience RTH, Horizon, and Loiter successfully. The Stratosurfer is so stable that flying it in Manual and Acro is easy. I have the basics of the Corewing F405 wing v2 down (took hours of study and frustration). Thanks, Litterbug for your recommendation of the Stratosurfer and the F405. My experience is limited, but they seem solid. It was quite a difficult journey arriving at this morning's fpv flight and I thank all of you who jumped in and helped me out (especially Litterbug). More adventures (and frustration) in the future, but I'm enjoying the ride.

 
Last edited:

Jo's squadron

Elite member
I finally arrived. I had my first, complete digital fpv flight with the Stratosurfer this morning. I launched it with Autolaunch (oh, wow, that was the best--no death dip or torque roll). I buzzed my neighborhood and did a victory roll (and loop . . . and inverted), and then landed with a 25 foot slide across the hard, dry earth. I've already experience RTH, Horizon, and Loiter successfully. The Stratosurfer is so stable that flying it in Manual and Acro is easy. I have the basics of the Corewing F405 wing v2 down (took hours of study and frustration). Thanks, Litterbug for your recommendation of the Stratosurfer and the F405. My experience is limited, but they seem solid. It was quite a difficult journey arriving at this morning's fpv flight and I thank all of you who jumped in and helped me out (especially Litterbug). More adventures (and frustration) in the future, but I'm enjoying the ride.
Congrats @toryander !
 

toryander

Active member
I would like to get the INAV black box information off of the fc. I've read that I can plug in the flight controller via USB and the folder navigation window will pop up via a new drive. I hear the Windows recognize Comm 6 that allows INAV to communicate with the fc, no drive is created for file navigation window (no message whatsoever) so I can't view the black box log file. I haven't been able to find more info on this online. Anyone have any experience with this?
 

LitterBug

Techno Nut
Moderator
I would like to get the INAV black box information off of the fc. I've read that I can plug in the flight controller via USB and the folder navigation window will pop up via a new drive. I hear the Windows recognize Comm 6 that allows INAV to communicate with the fc, no drive is created for file navigation window (no message whatsoever) so I can't view the black box log file. I haven't been able to find more info on this online. Anyone have any experience with this?
Did you put an SD card in the FC when you put it together? Did you enable logging?
 

toryander

Active member
Today I tested the range of my fpv setup. I flew over 1600 meters away and still had decent control. I don't have long range equipment, yet. I was using my Pocket tx with 250 mw to an er6 rx. My Avatar Mini 1s Lite was using 300mw to my Goggles L. I was pleased with that. I guess to go further I would need a crossfire rx with the nano crossfire module? Then perhaps the Avatar GT kit?
 

LitterBug

Techno Nut
Moderator
To put your FC into the mode where you can read the SC card, go into the CLI and type msc and hit return. The FC will reboot and now you can see the SD card on your computer.
 

LitterBug

Techno Nut
Moderator
1000011828.jpg
1000011817.jpg

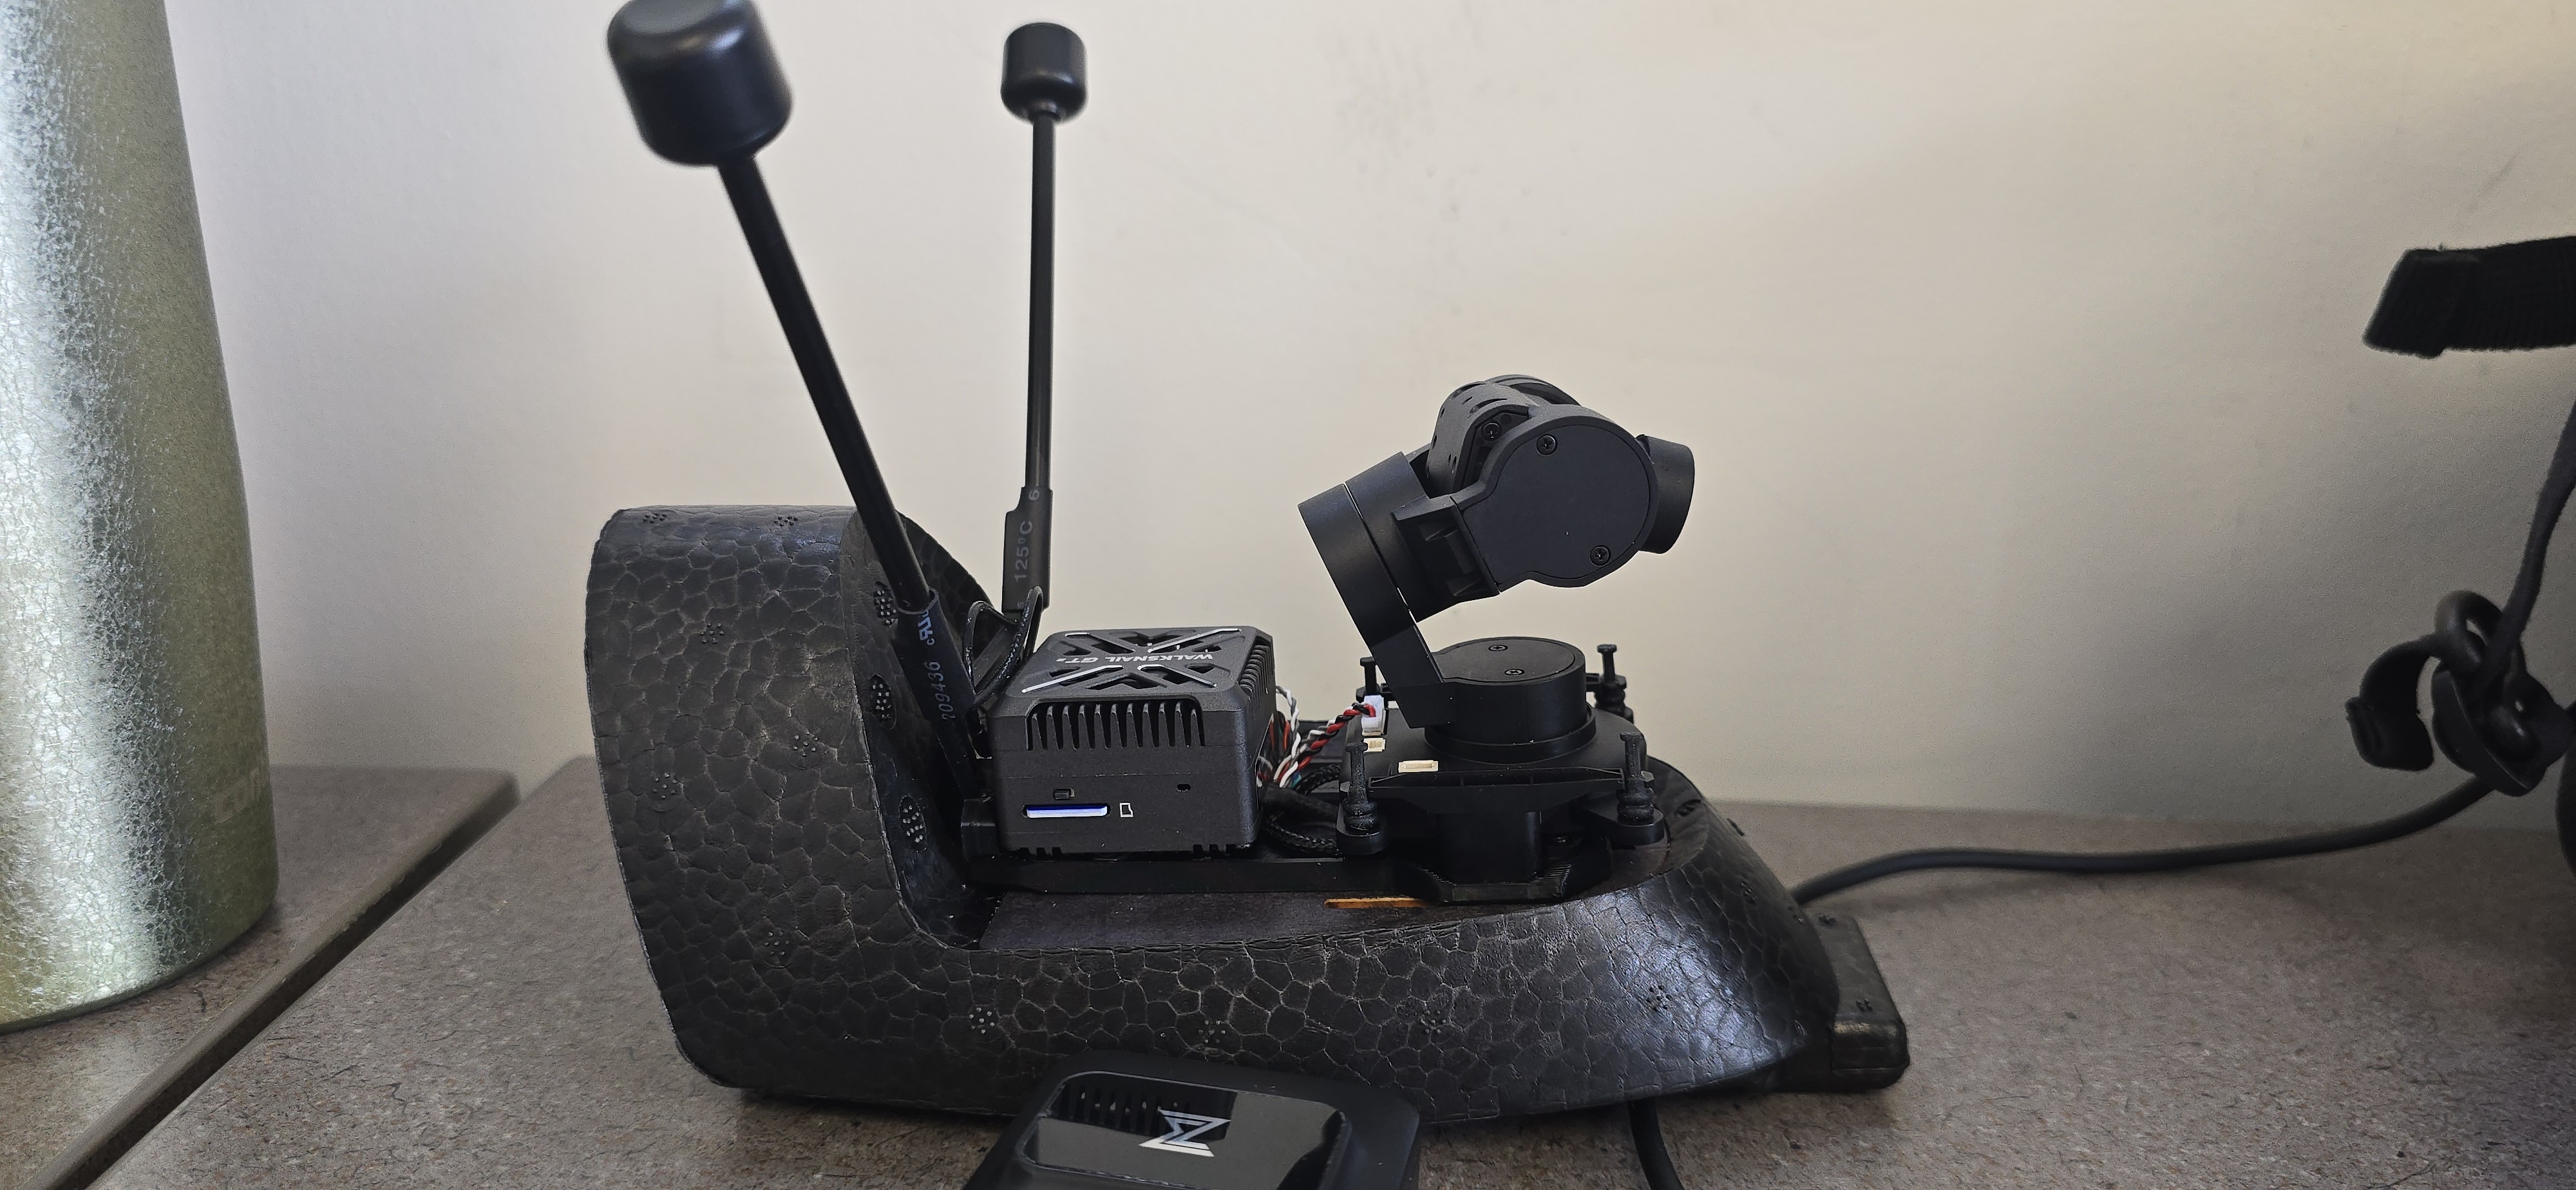
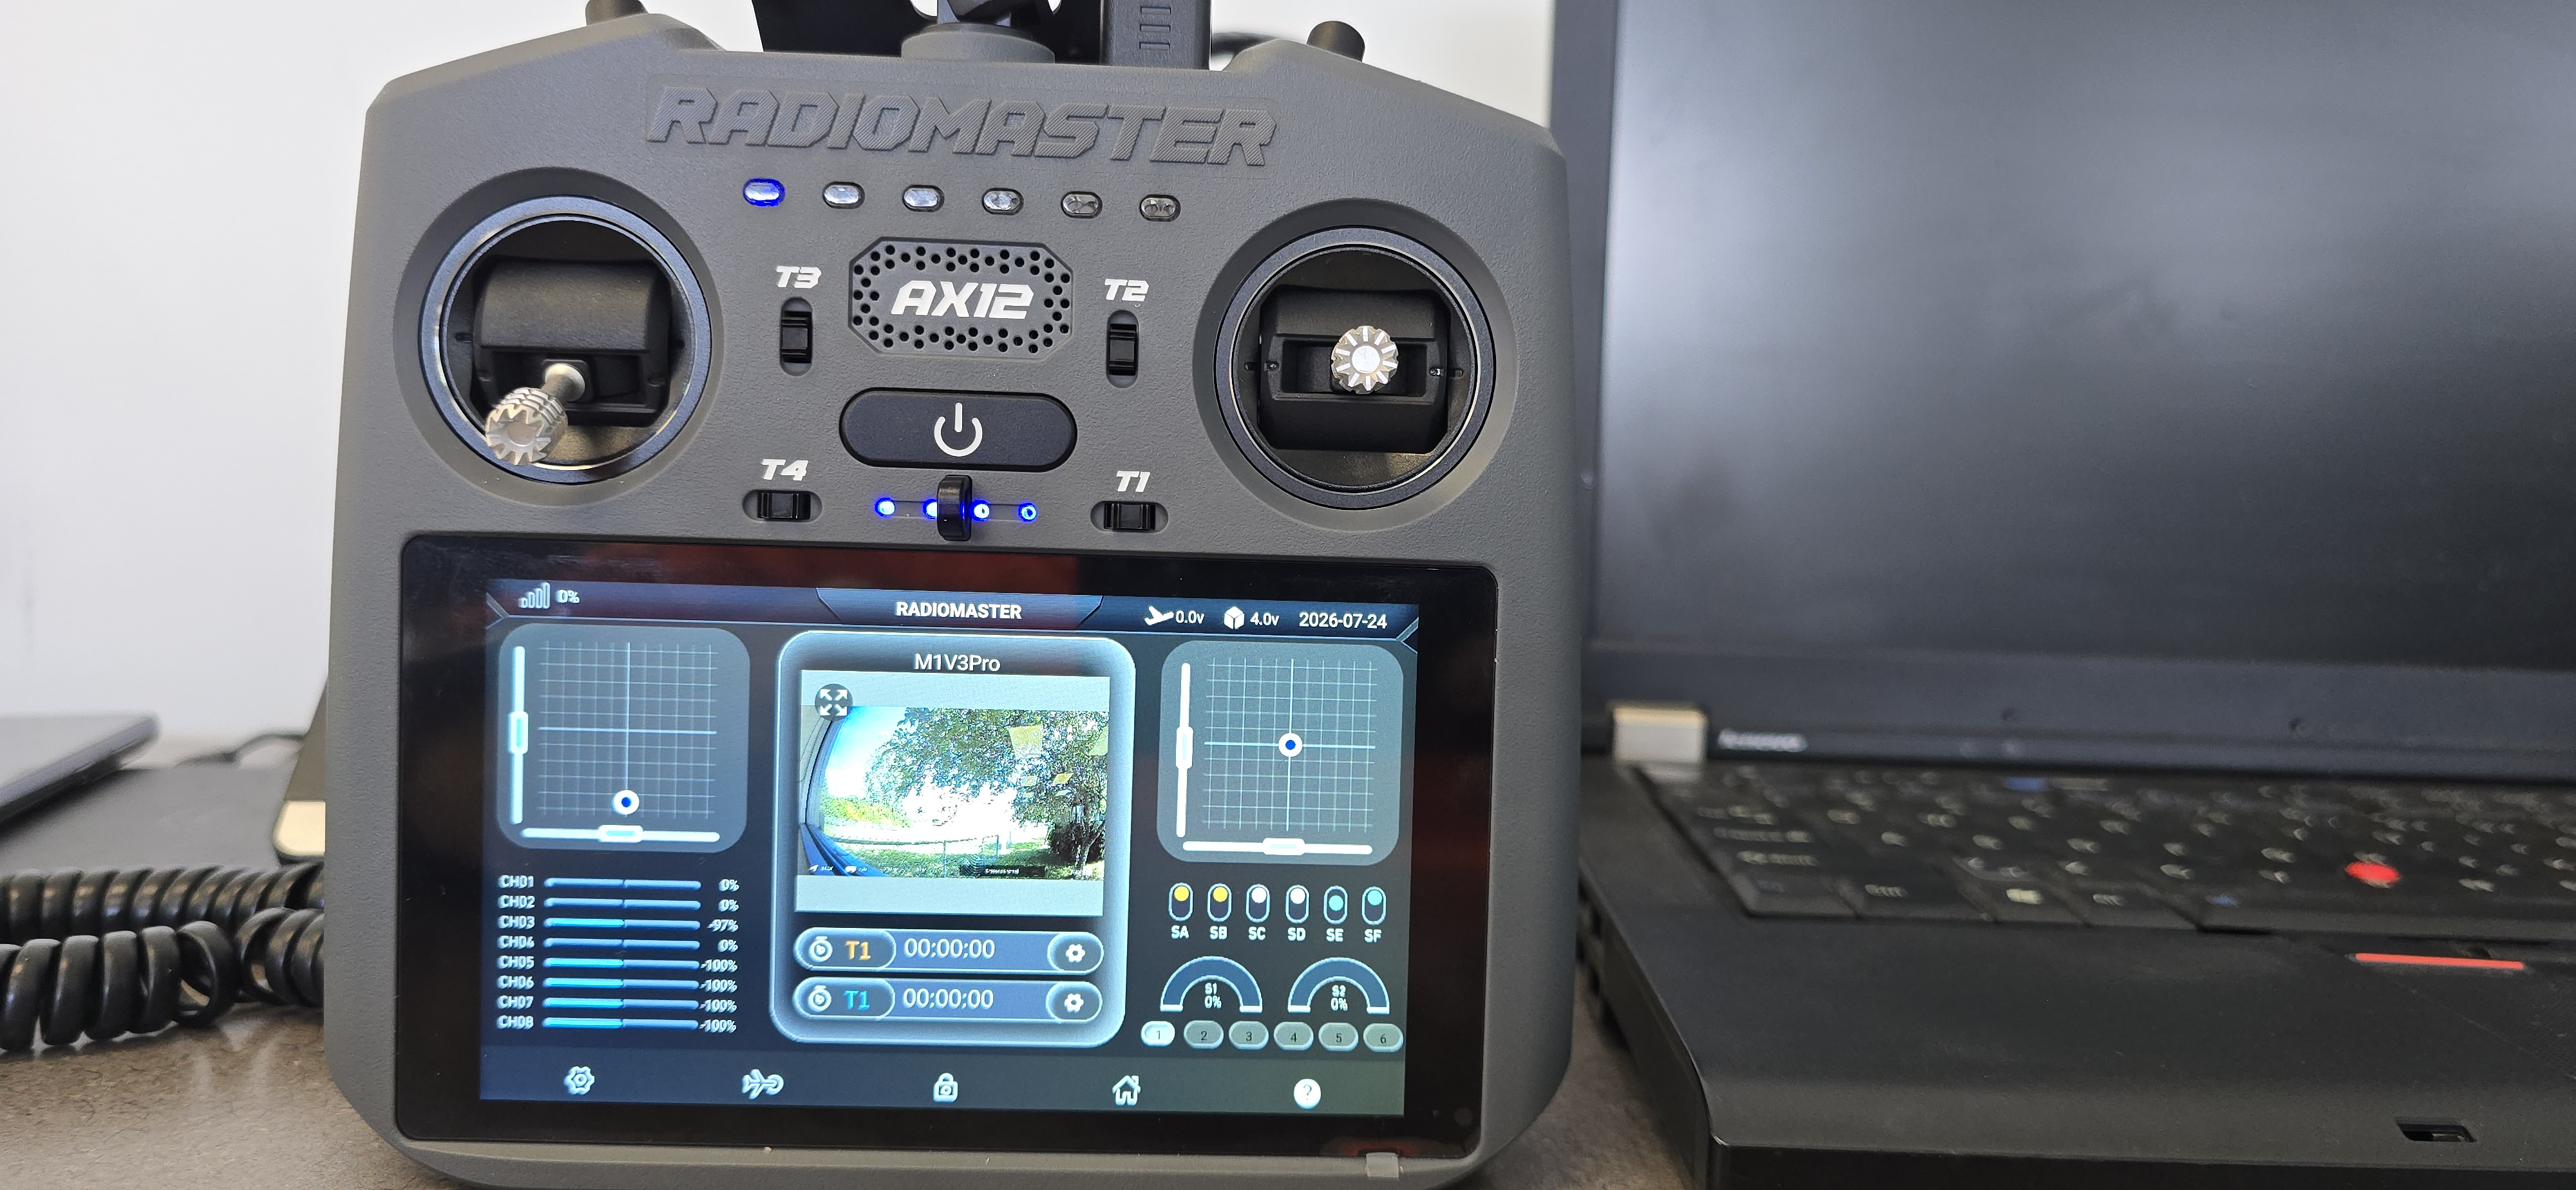
Was updating the firmware on my new FPV setup with the GT2 and GM3 V2. Been playing with the Radiomaster AX12 at work too with my Walksnail VRX hooked up. Video feed in the center can be enlarged to full screen by clicking the upper left corner of the image.
 

LitterBug

Techno Nut
Moderator
I have both the Walksnail VRX and GogglesX. My range varies by the direction I fly and how many tree lines I fly behind. I have not yet flown the GT2 to see what it does for penetration. I have a bunch of different antennas to test too. Generally speaking, I will get better range from the VRX up on a pole than I would with the GogglesX due to the obvious better antenna placement. I don't really go out more than a mile where I normally fly and usually don't max out TX power. I can only use the headtracking with the GogglesX. Planning on putting the Moonlight setup back on another FPV pod for the StratoSurfer with just a pan servo like I had originally to do comparison of the cameras and VTXes. Looking for fan options to mount to the Moonlight VTX. The one on the GT2 is great at keeping that TX cool on the ground. Wonder if it will bolt up directly to the ML.
 

toryander

Active member
The styrofoam hinge on my Stratosurfer is looking thin on the ailerons and flaps (cracking). I'm going to do the hot glue reinforcement learned from my flite test builds. Hope it goes well.